Wenjun Yu

I build robotic systems, embedded electronics and sensor-led prototypes.

PiPER active scanning

Active vision for nature-surveying robots

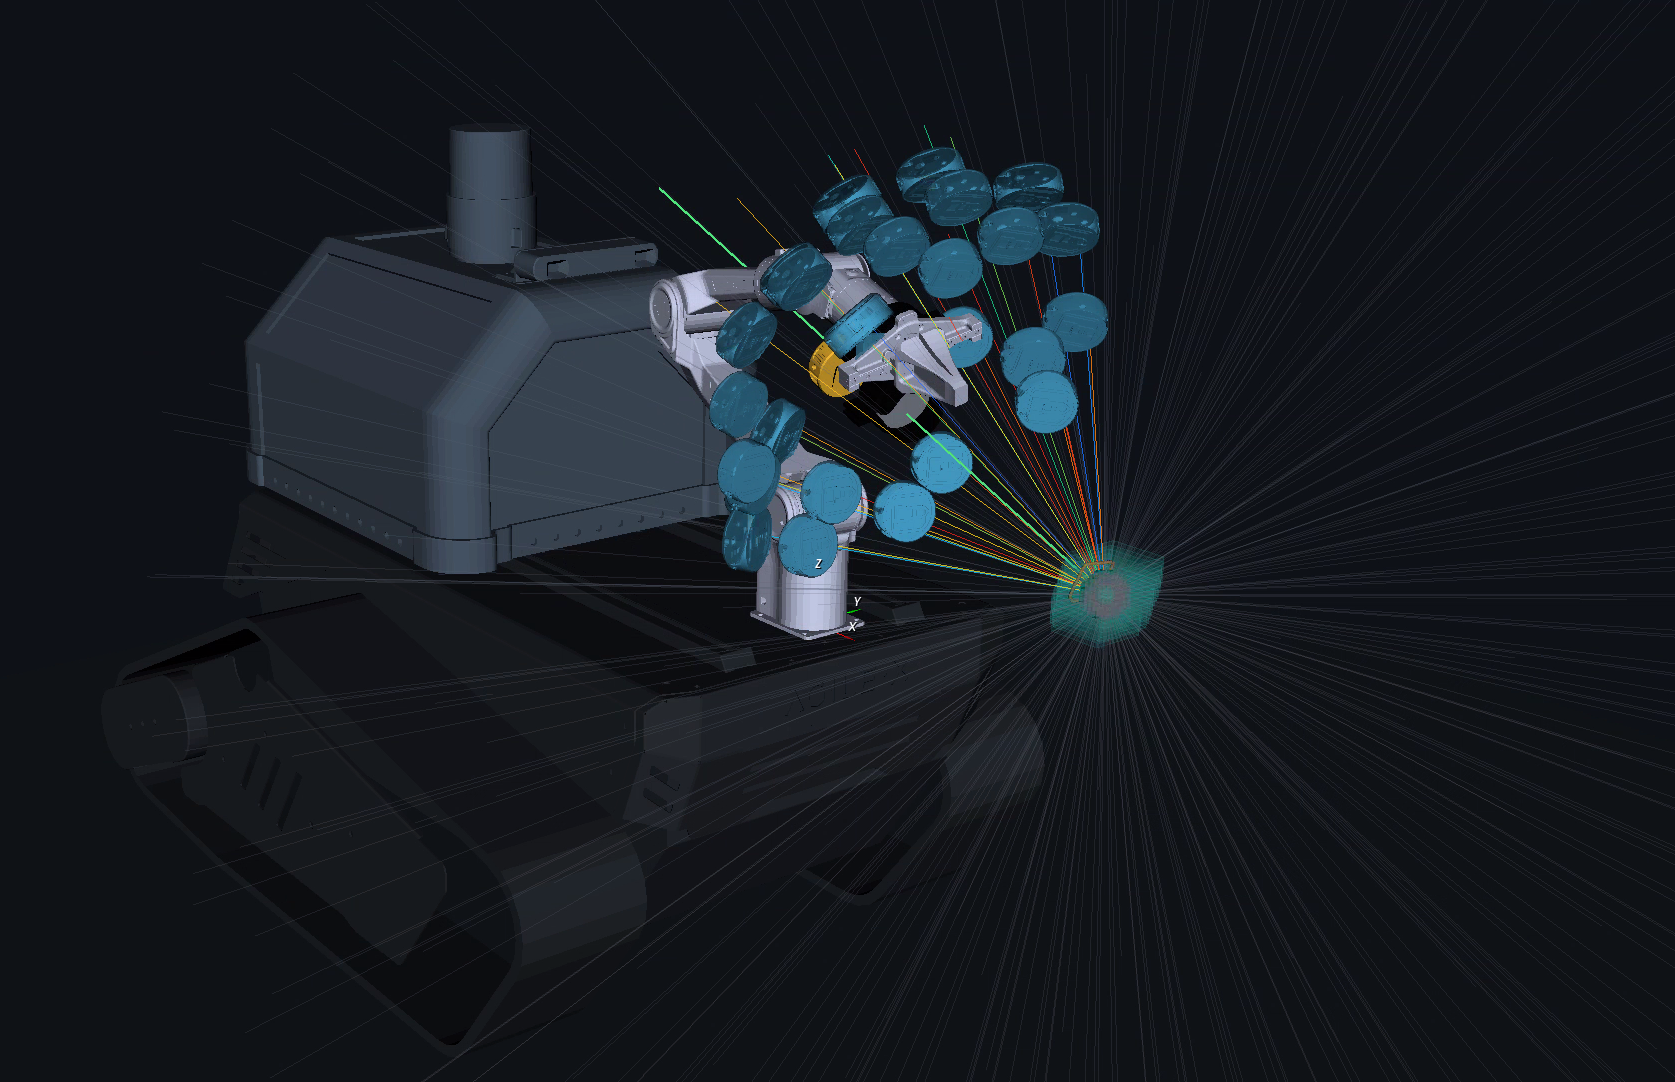
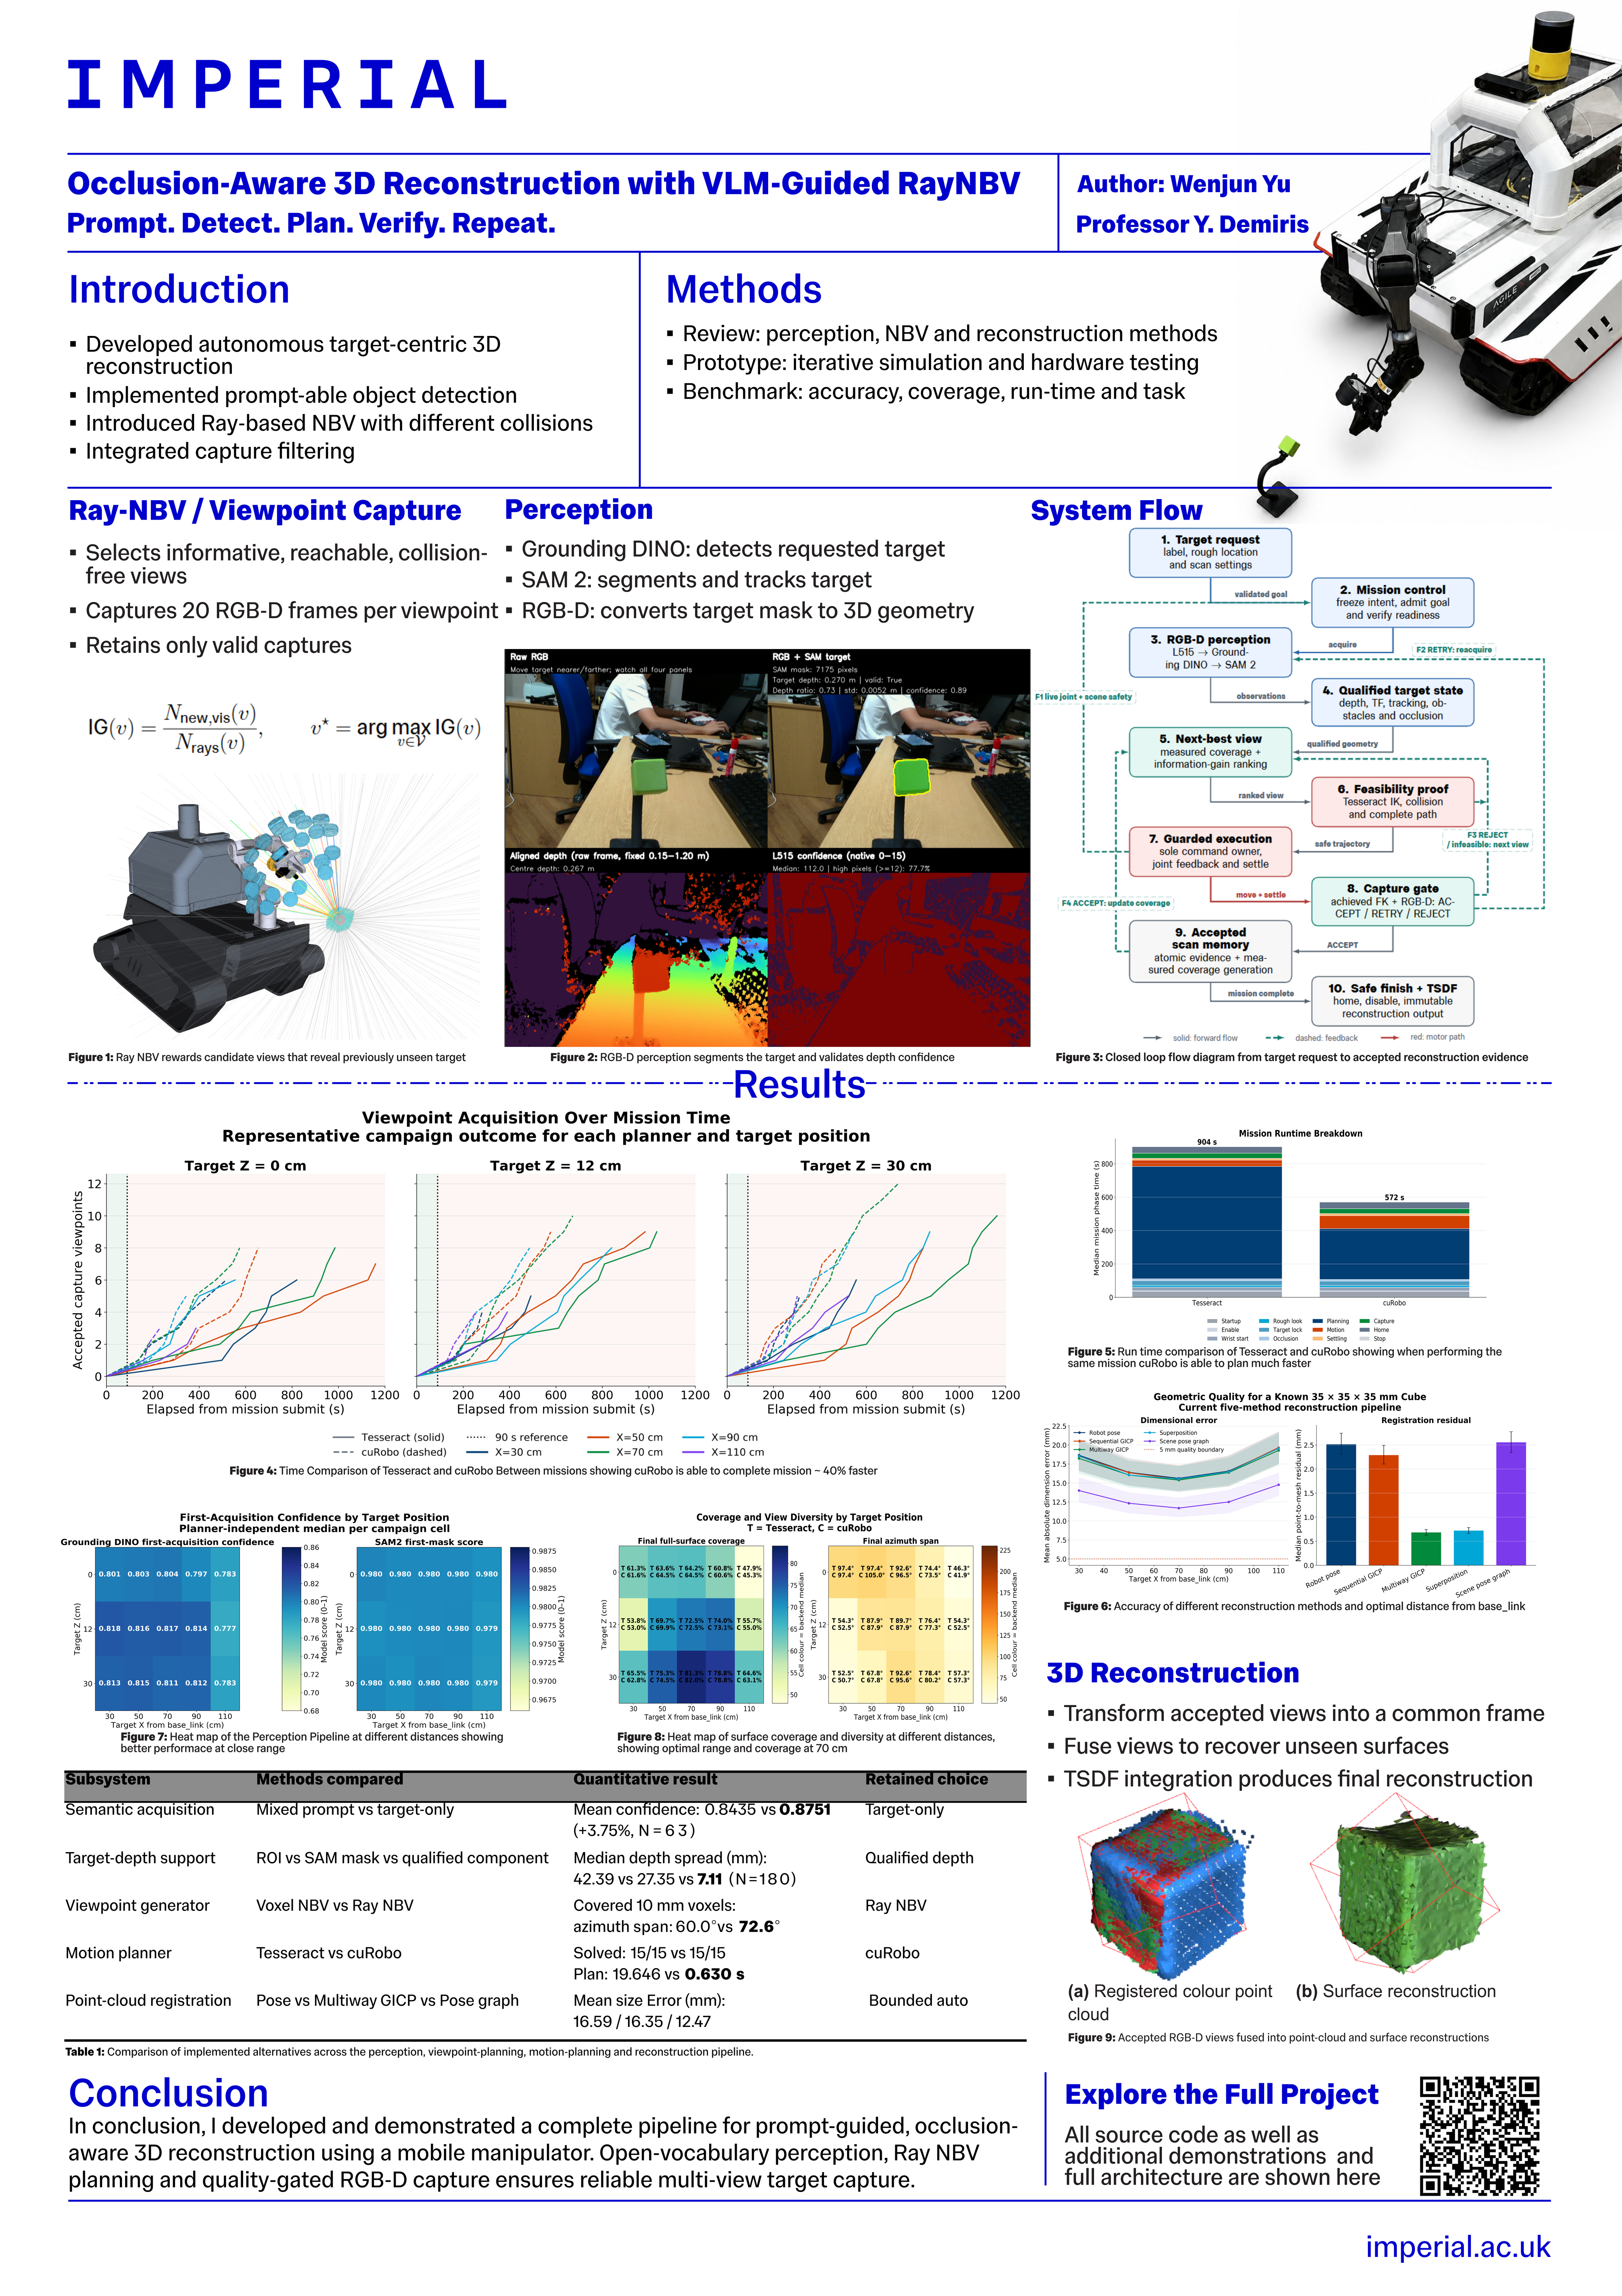
I built an active-vision pipeline that deploys the arm to inspect targets obscured from a nature-surveying robot’s base camera.

View project repositoryView project poster
What I built

What I built

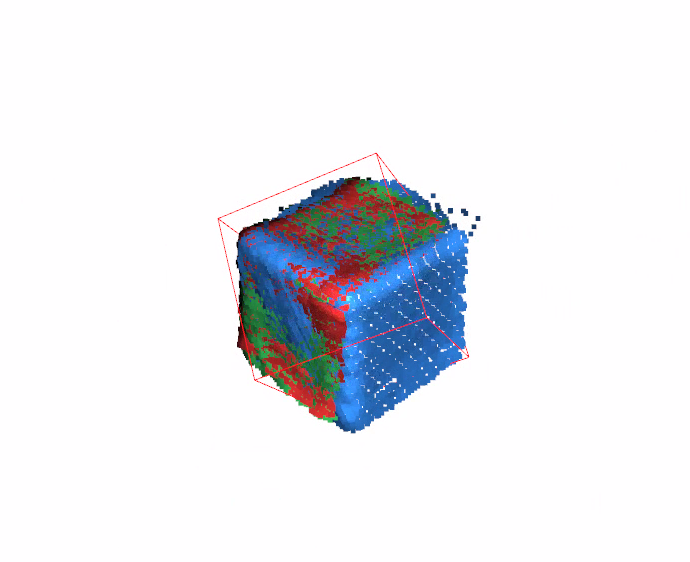
I developed a ROS 2 pipeline for open-label target detection, mask tracking, depth projection, next-best-view planning and target-only RGB-D reconstruction. The intended surveying workflow starts with the base camera, deploys the arm for a clearer view, then repositions the base between scans if the target remains obscured. This repository provides the arm-level perception, planning and capture pipeline; the wider platform coordinates base repositioning.

Capabilities

  • Open-label RGB-D perception with GroundingDINO and SAM2
  • Occlusion-aware next-best-view planning with Tesseract and cuRobo
  • Capture validation and target-only multi-view reconstruction
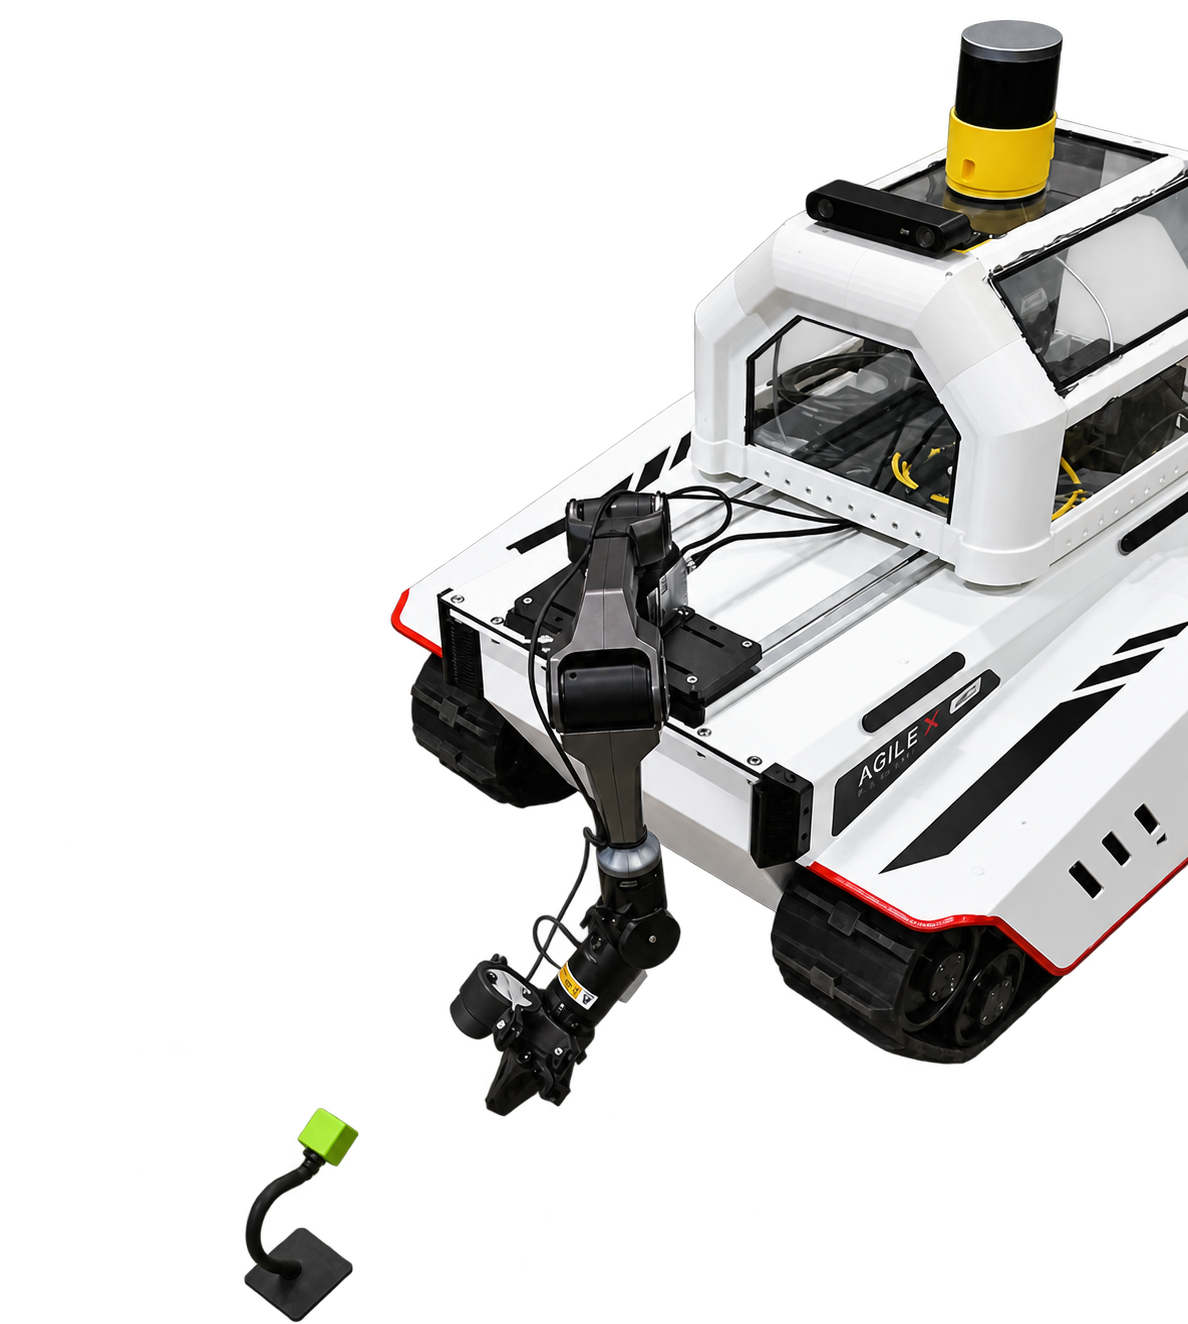
White tracked PiPER mobile robot with a robotic arm and gripper beside a green target.
PiPER arm on a tracked mobile platform.

Lock-in amplifier

Analogue detection and STM32F446 digital processing

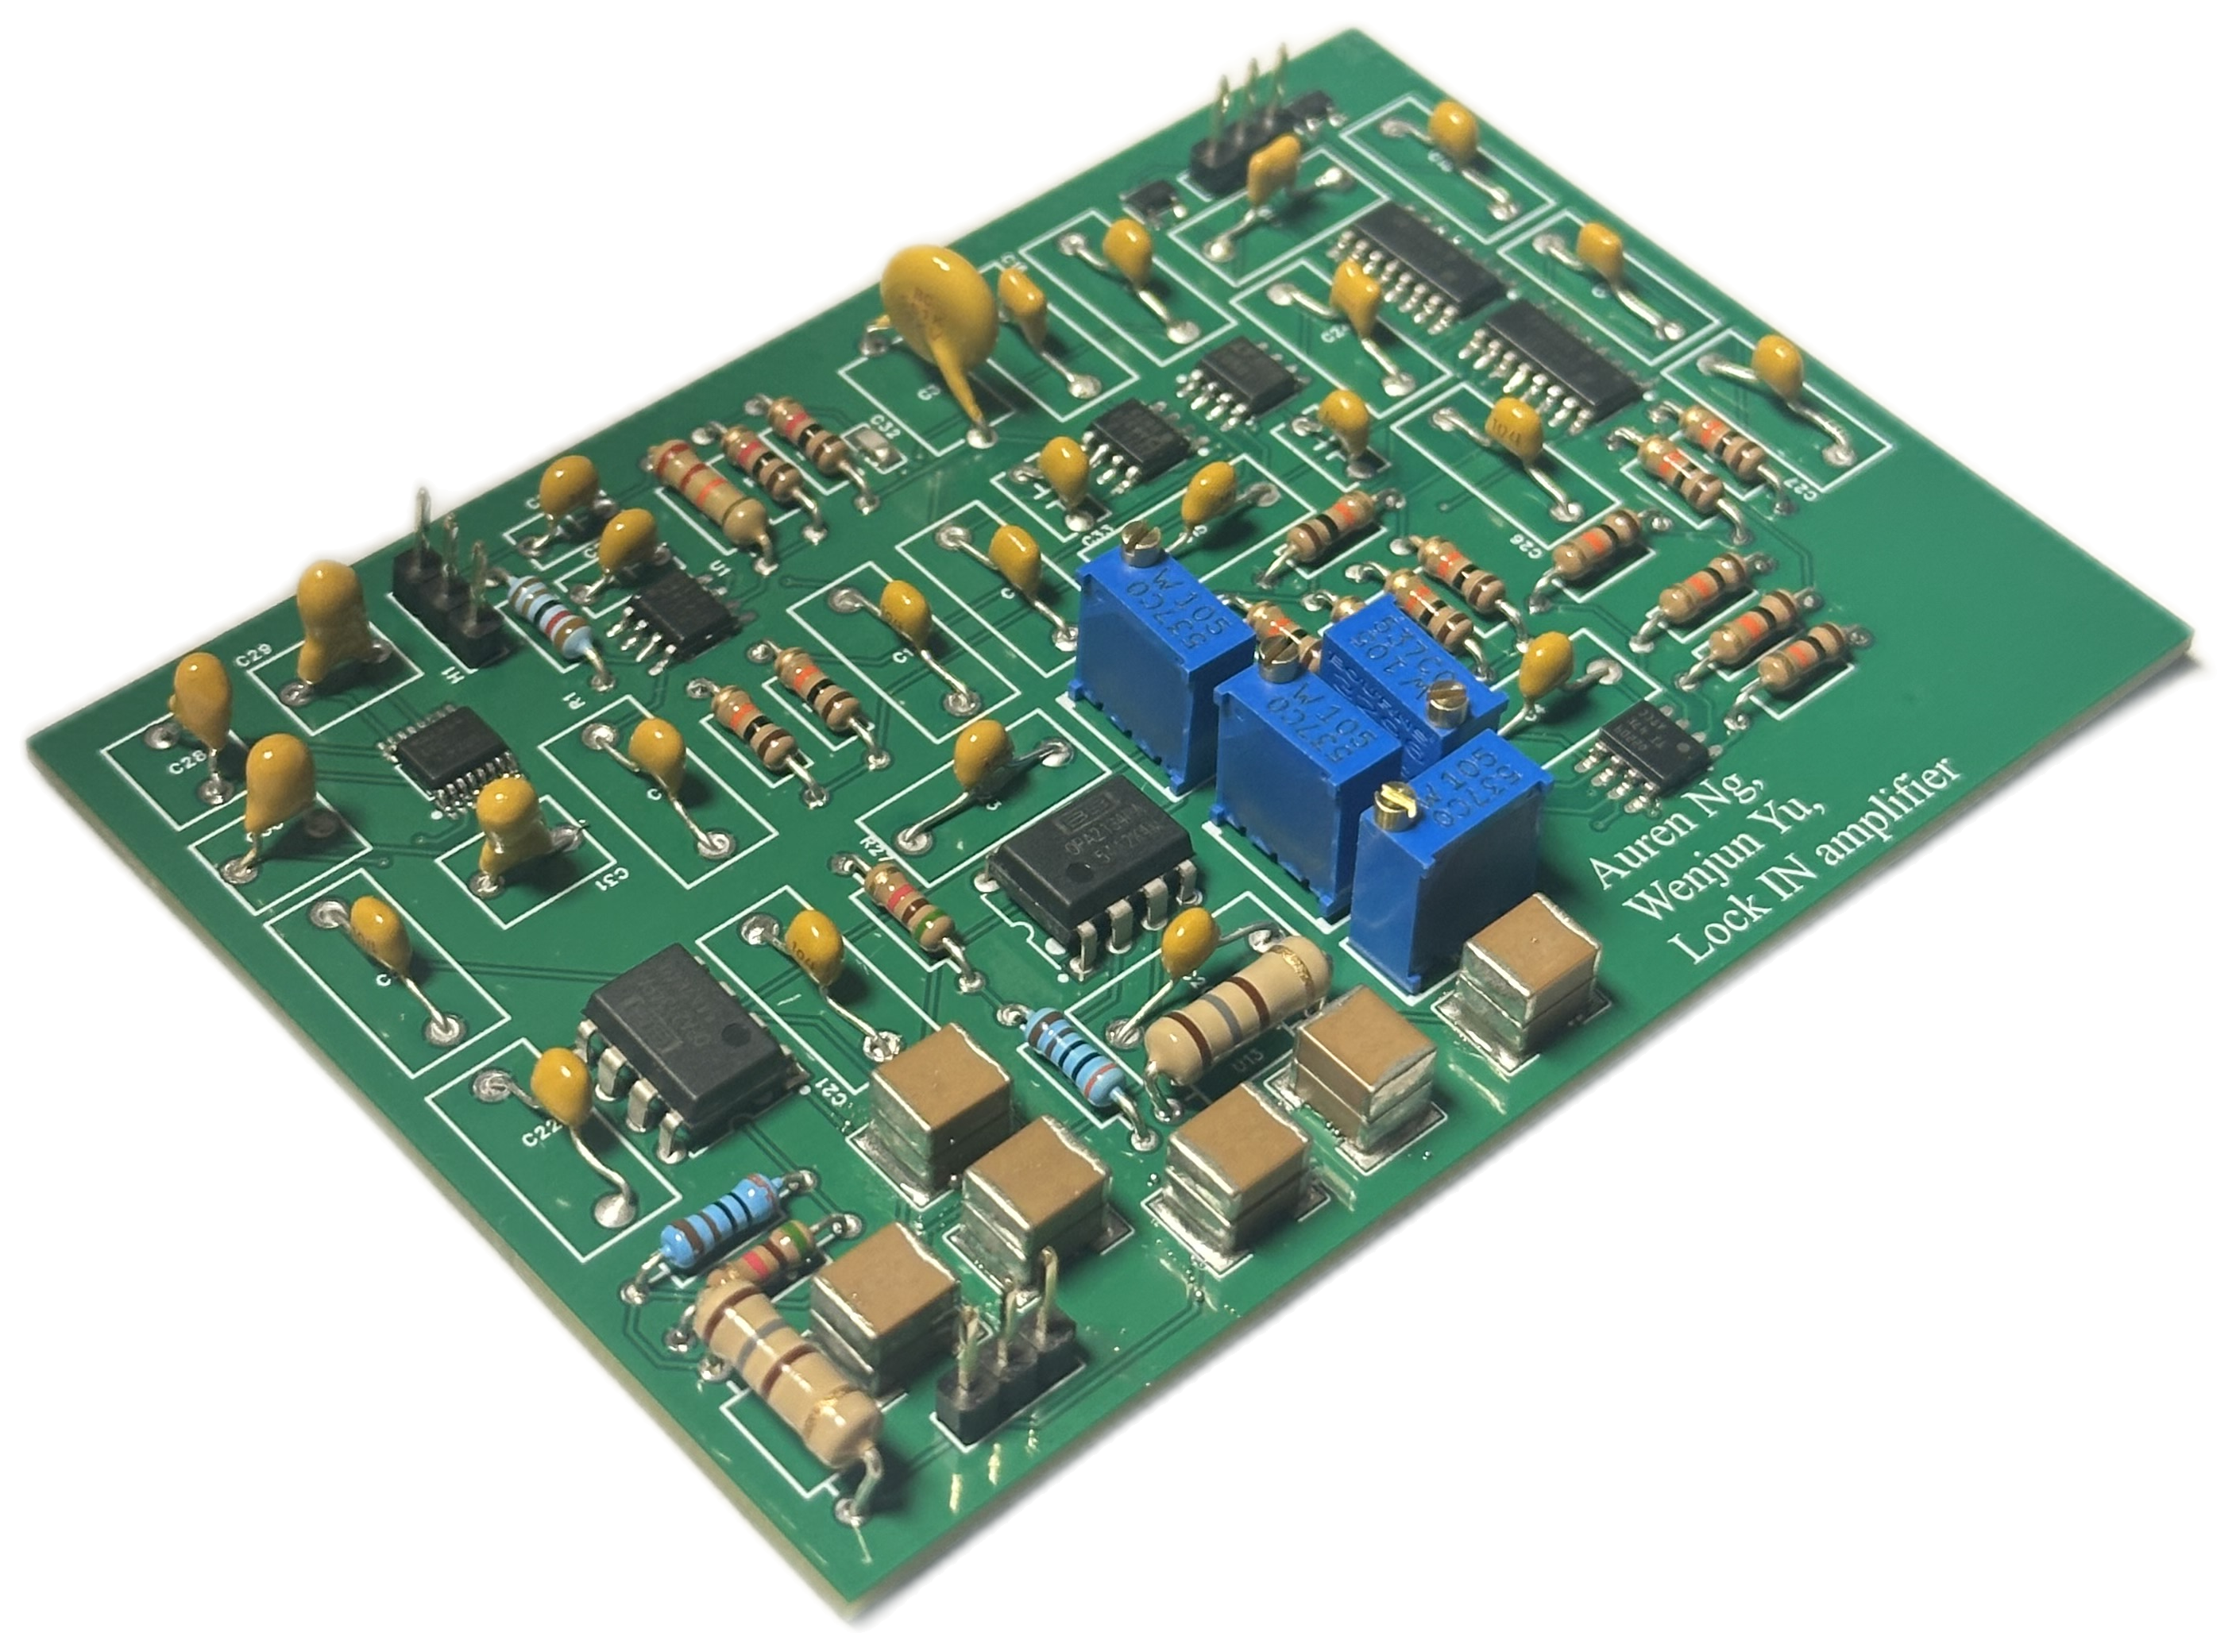
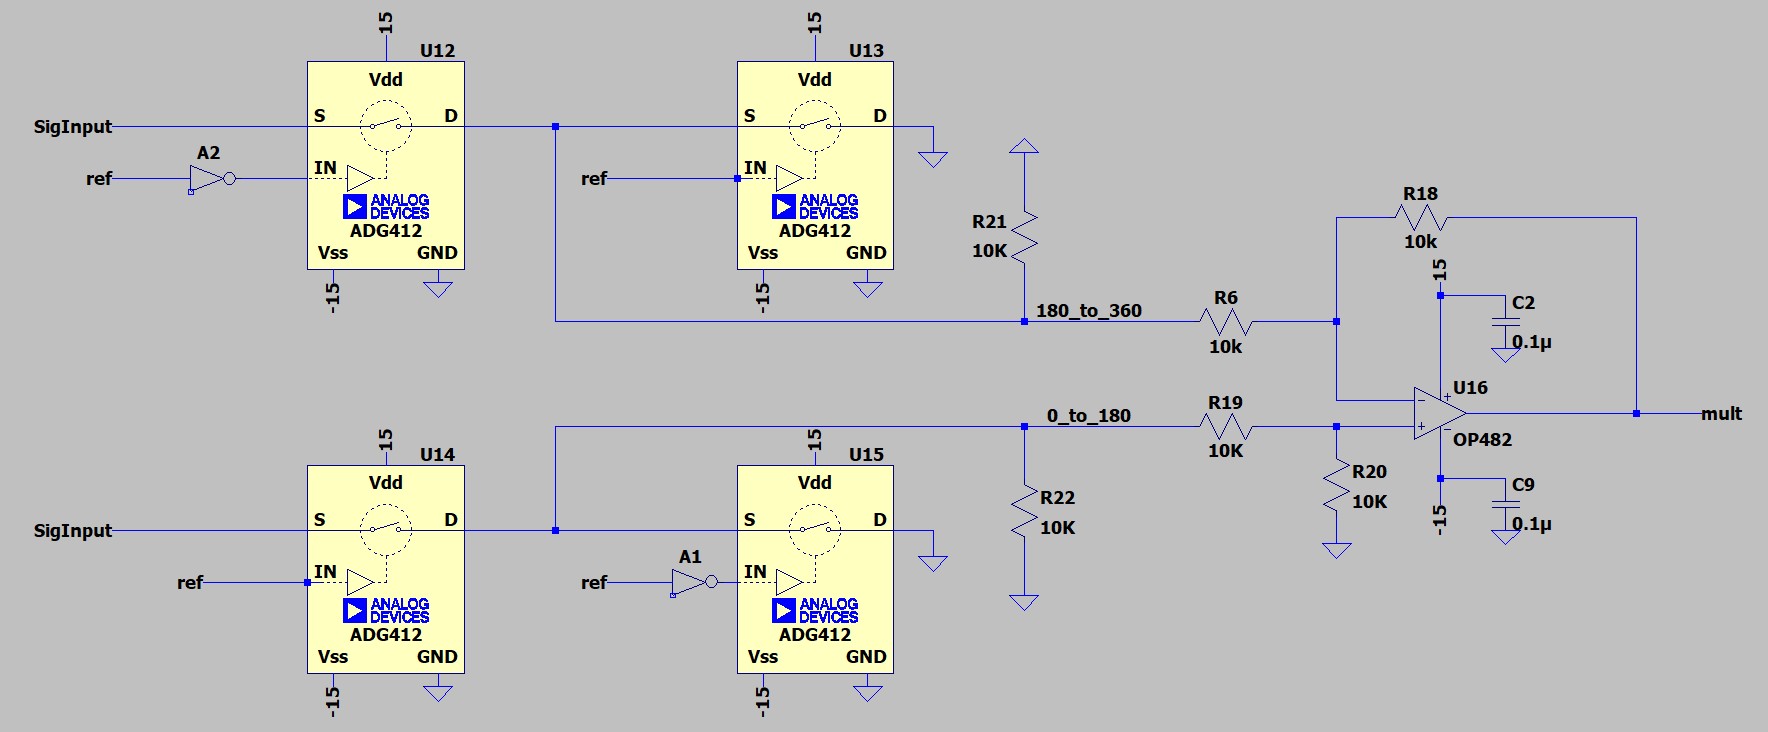
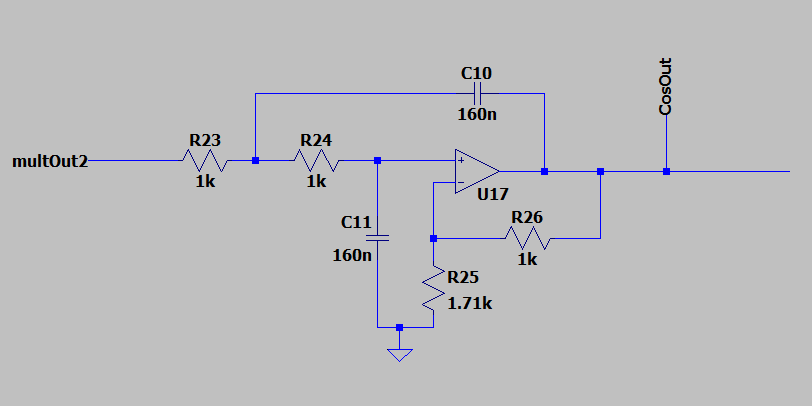
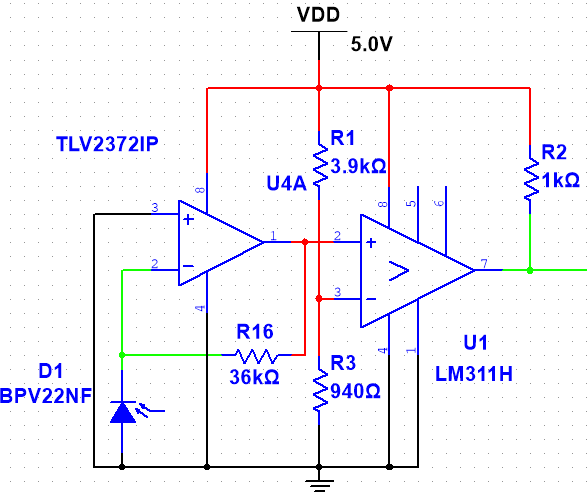
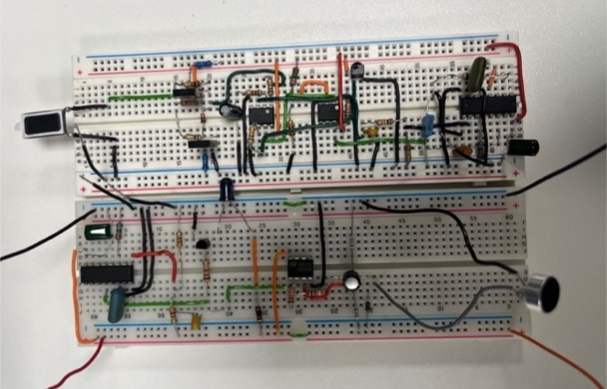
I contributed to a collaborative lock-in amplifier project combining analogue detection circuits with STM32F446 reference generation and acquisition.

GitHub · private
What I built

Collaborative electronics and embedded development

This collaborative project brings together analogue conditioning and multiplier/filter studies with STM32F446 reference generation, ADC/DMA acquisition and UART data output. The repository preserves circuit studies, PCB manufacturing files, peripheral configuration and a separate FIR filtering implementation. The architecture distinguishes the acquisition path from the filtering library.

Capabilities

  • Analogue conditioning, multiplier and filter design studies
  • STM32F446 reference generation, ADC/DMA and UART acquisition
  • PCB manufacturing outputs and a separate C FIR library
Assembled lock-in amplifier PCB, isolated from the bench without changing its components
Assembled analogue front-end PCB for the lock-in amplifier.

Wireless sensor nodes

Patient health signals and room-condition monitoring

I designed wearable PPG and motion-sensing boards alongside an environmental node that monitors room conditions relevant to patient care.

GitHub · private
What I built

Wearable boards and environmental monitoring

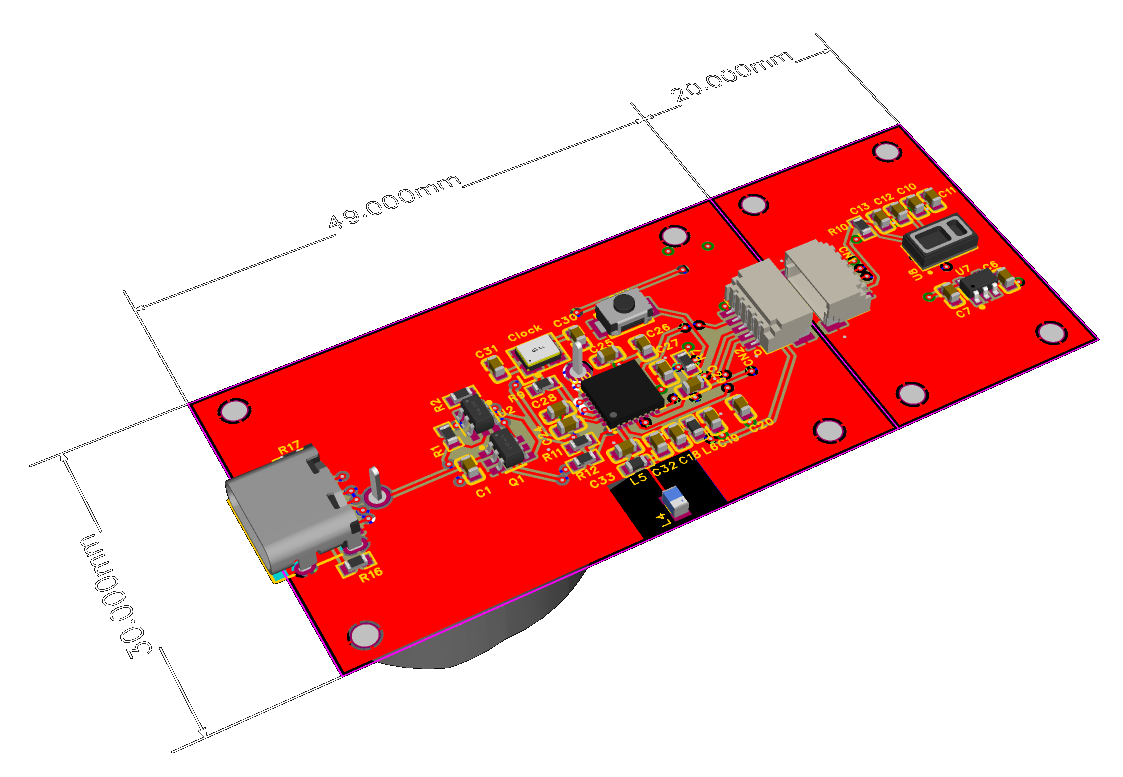
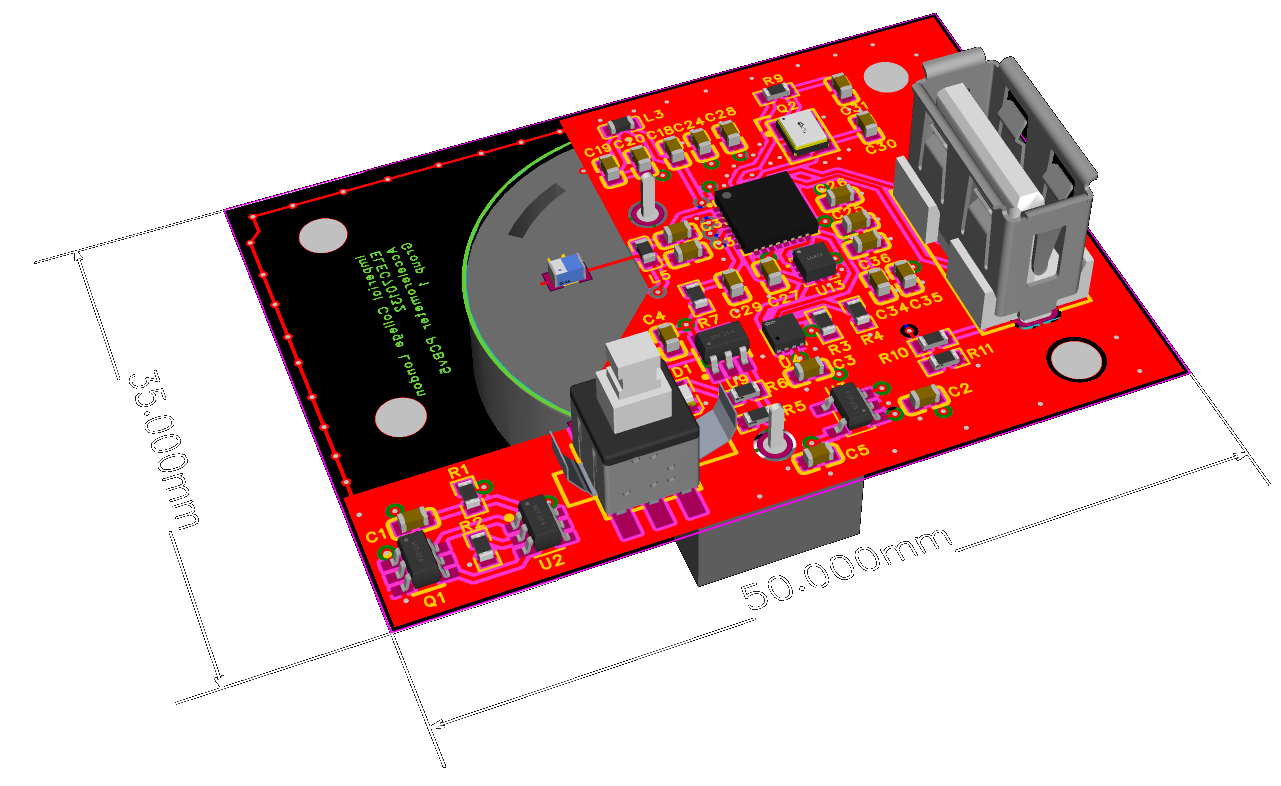
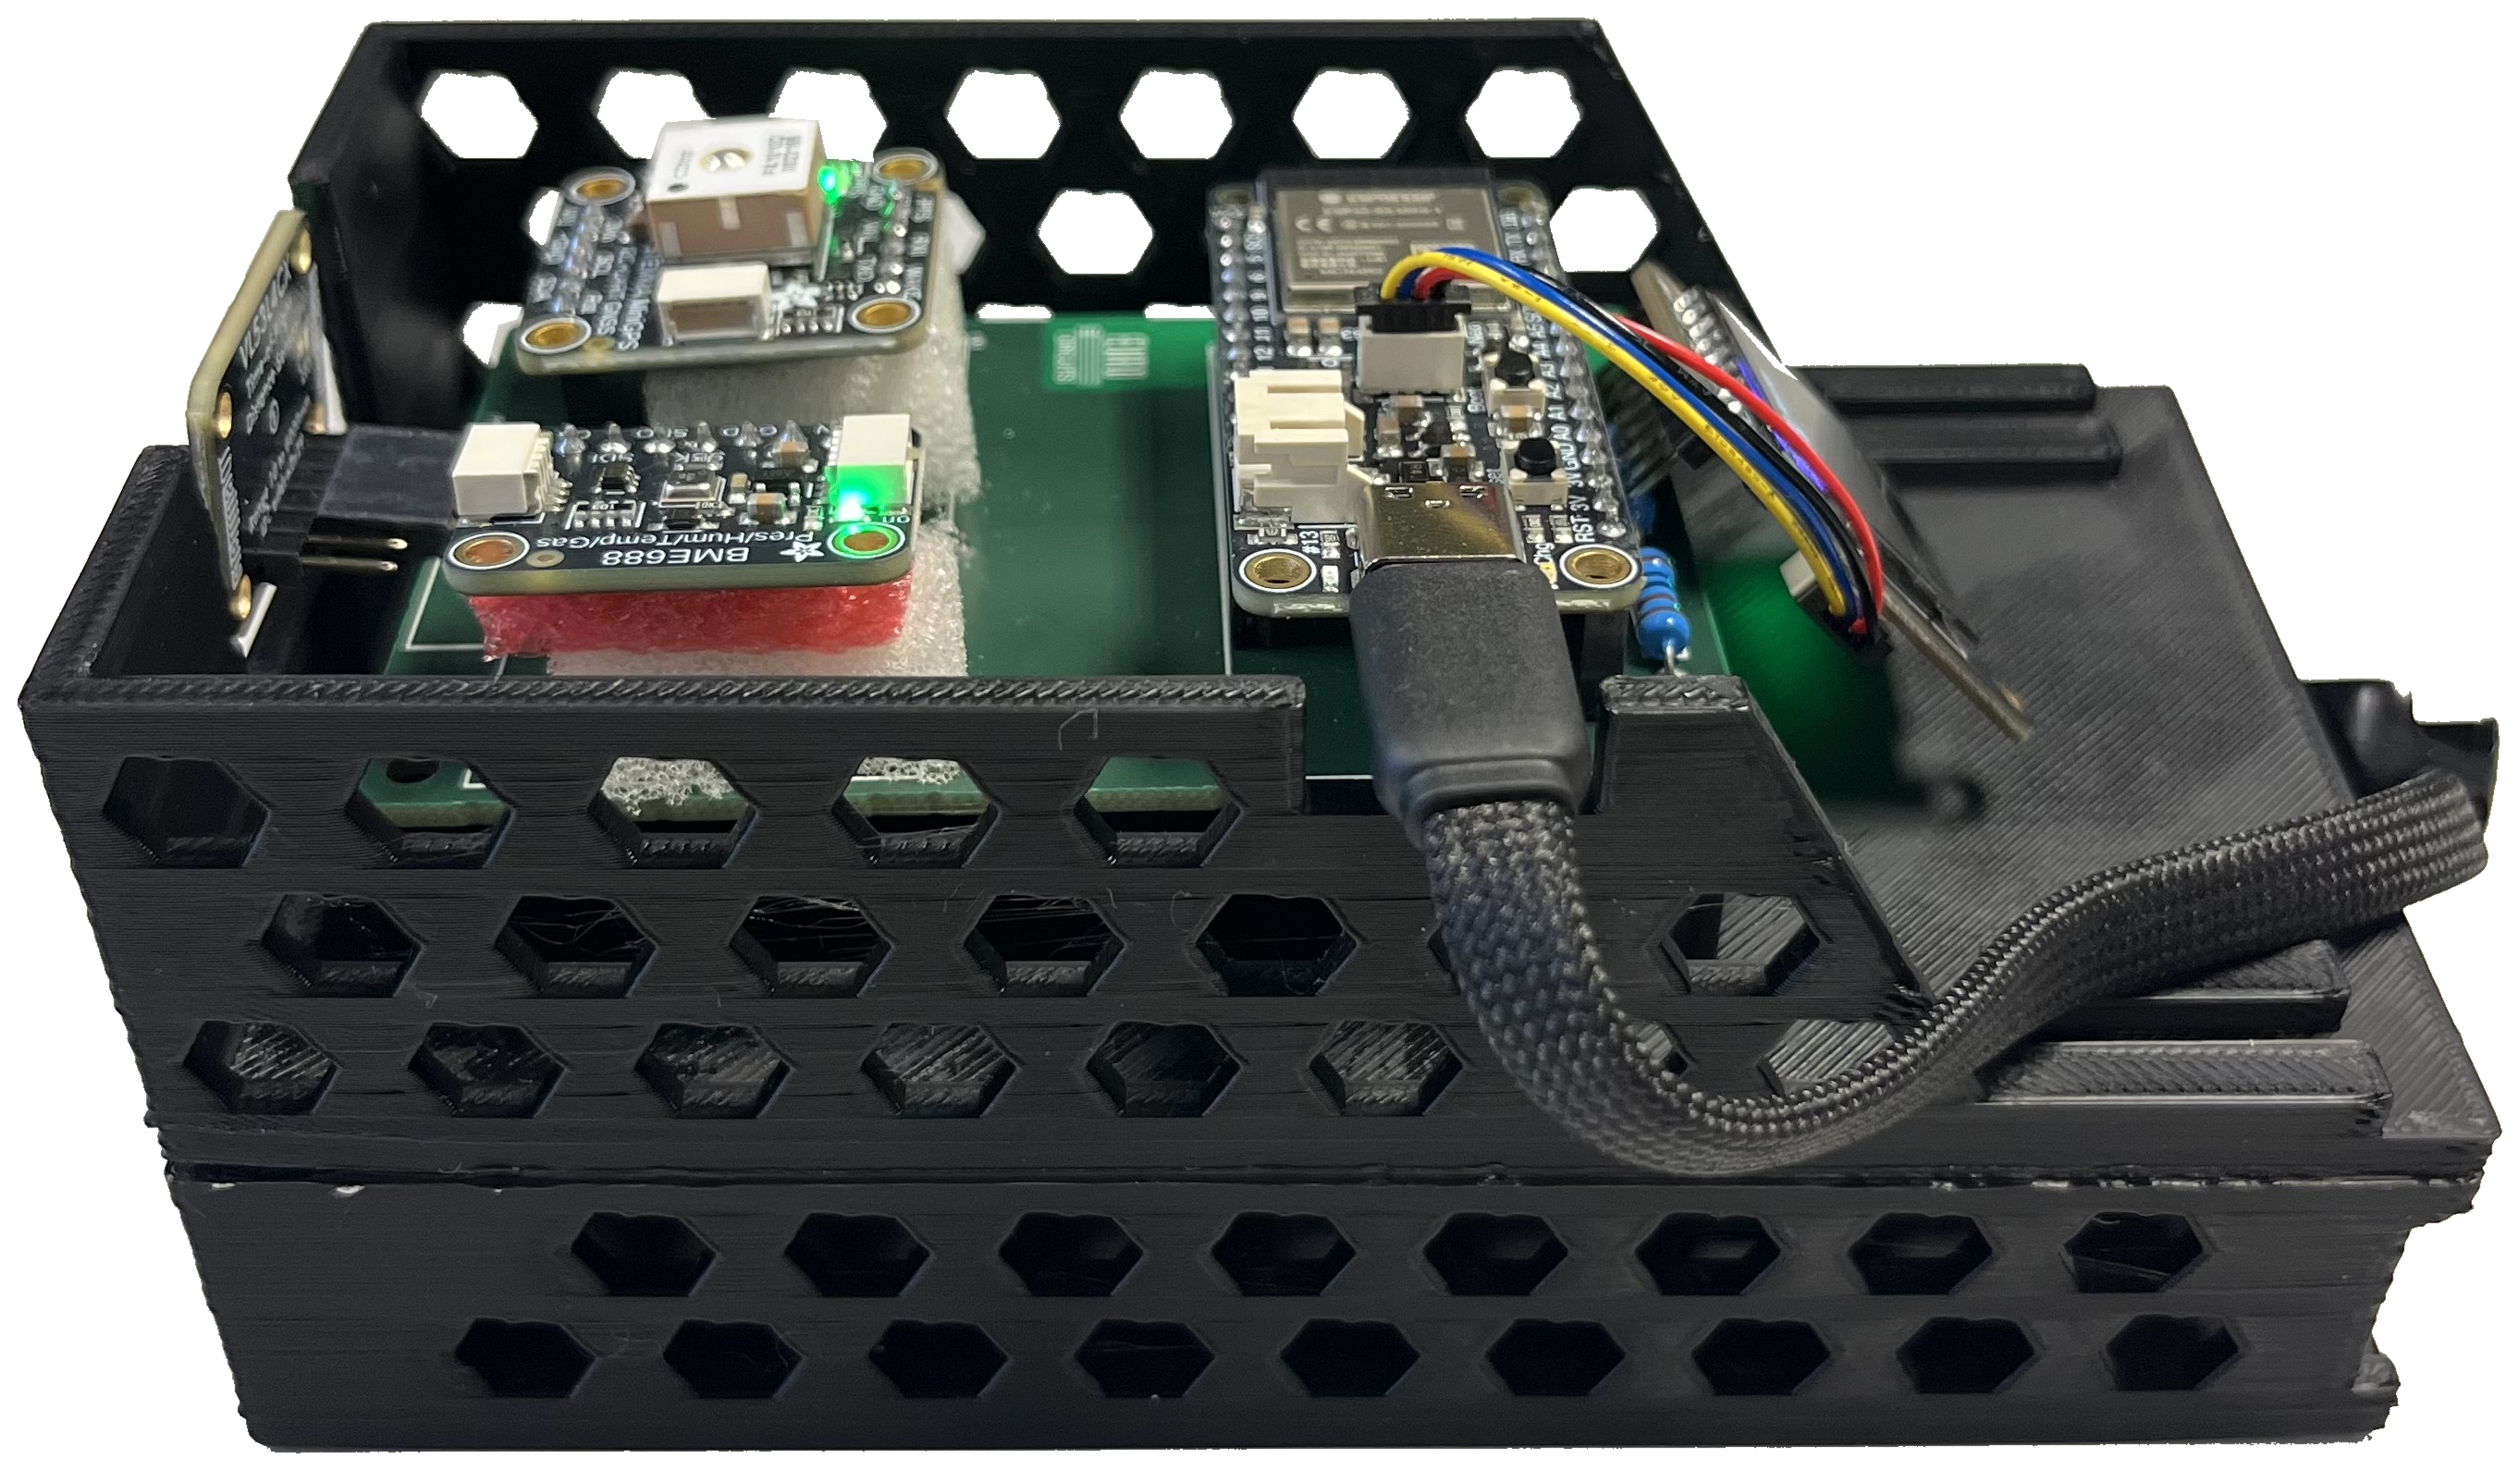
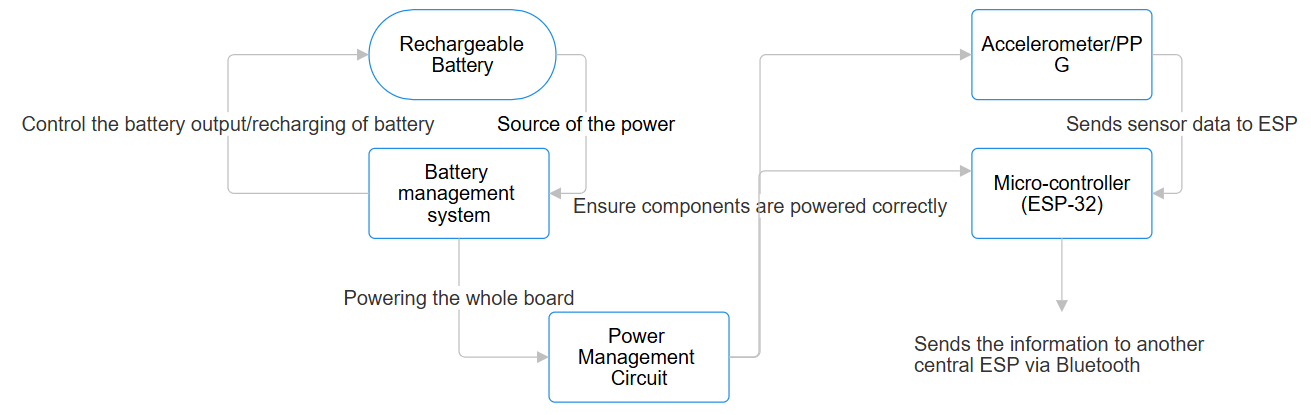
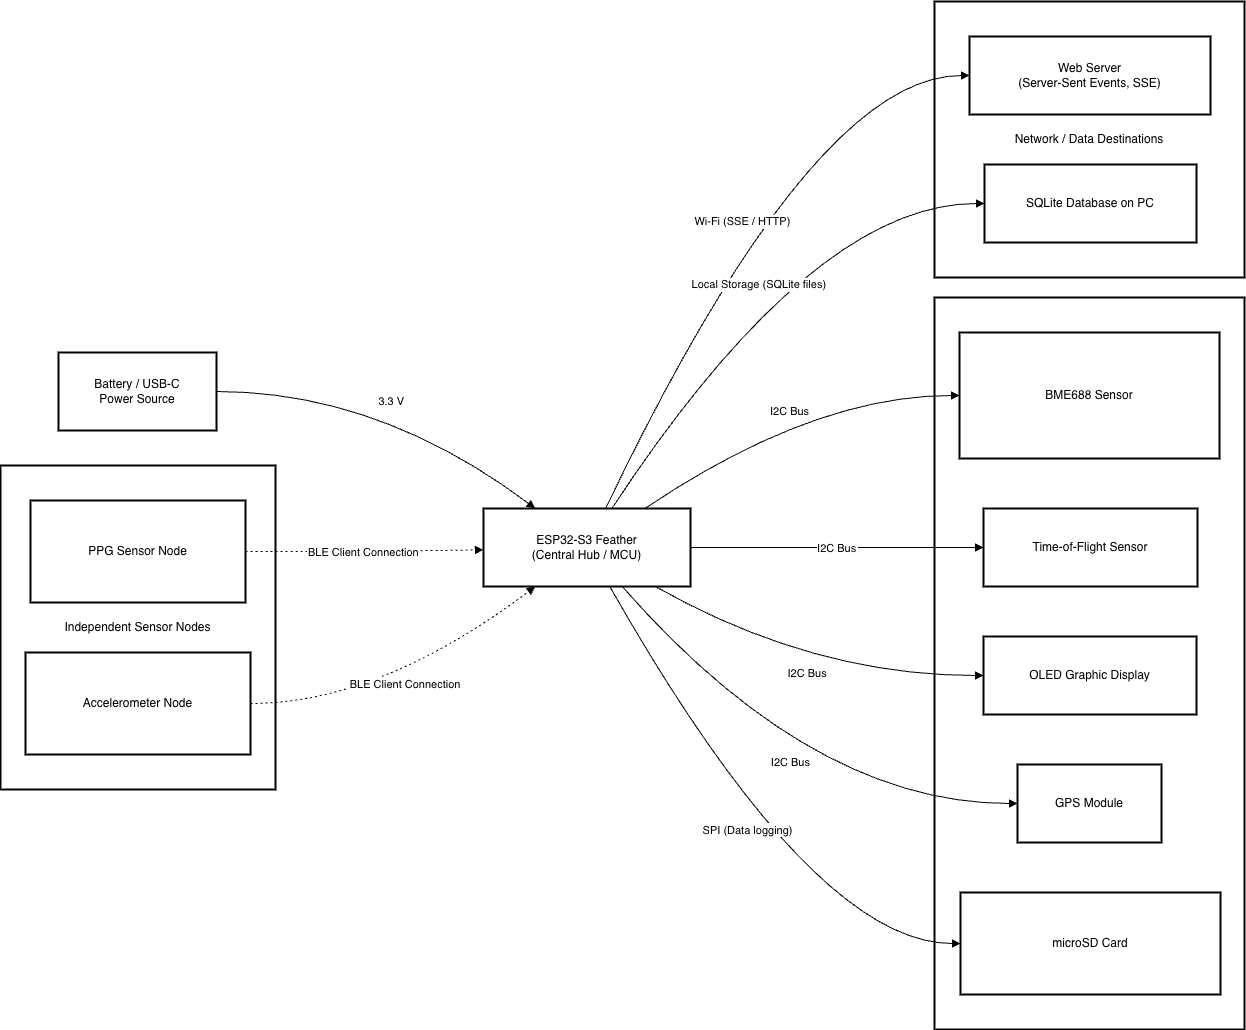
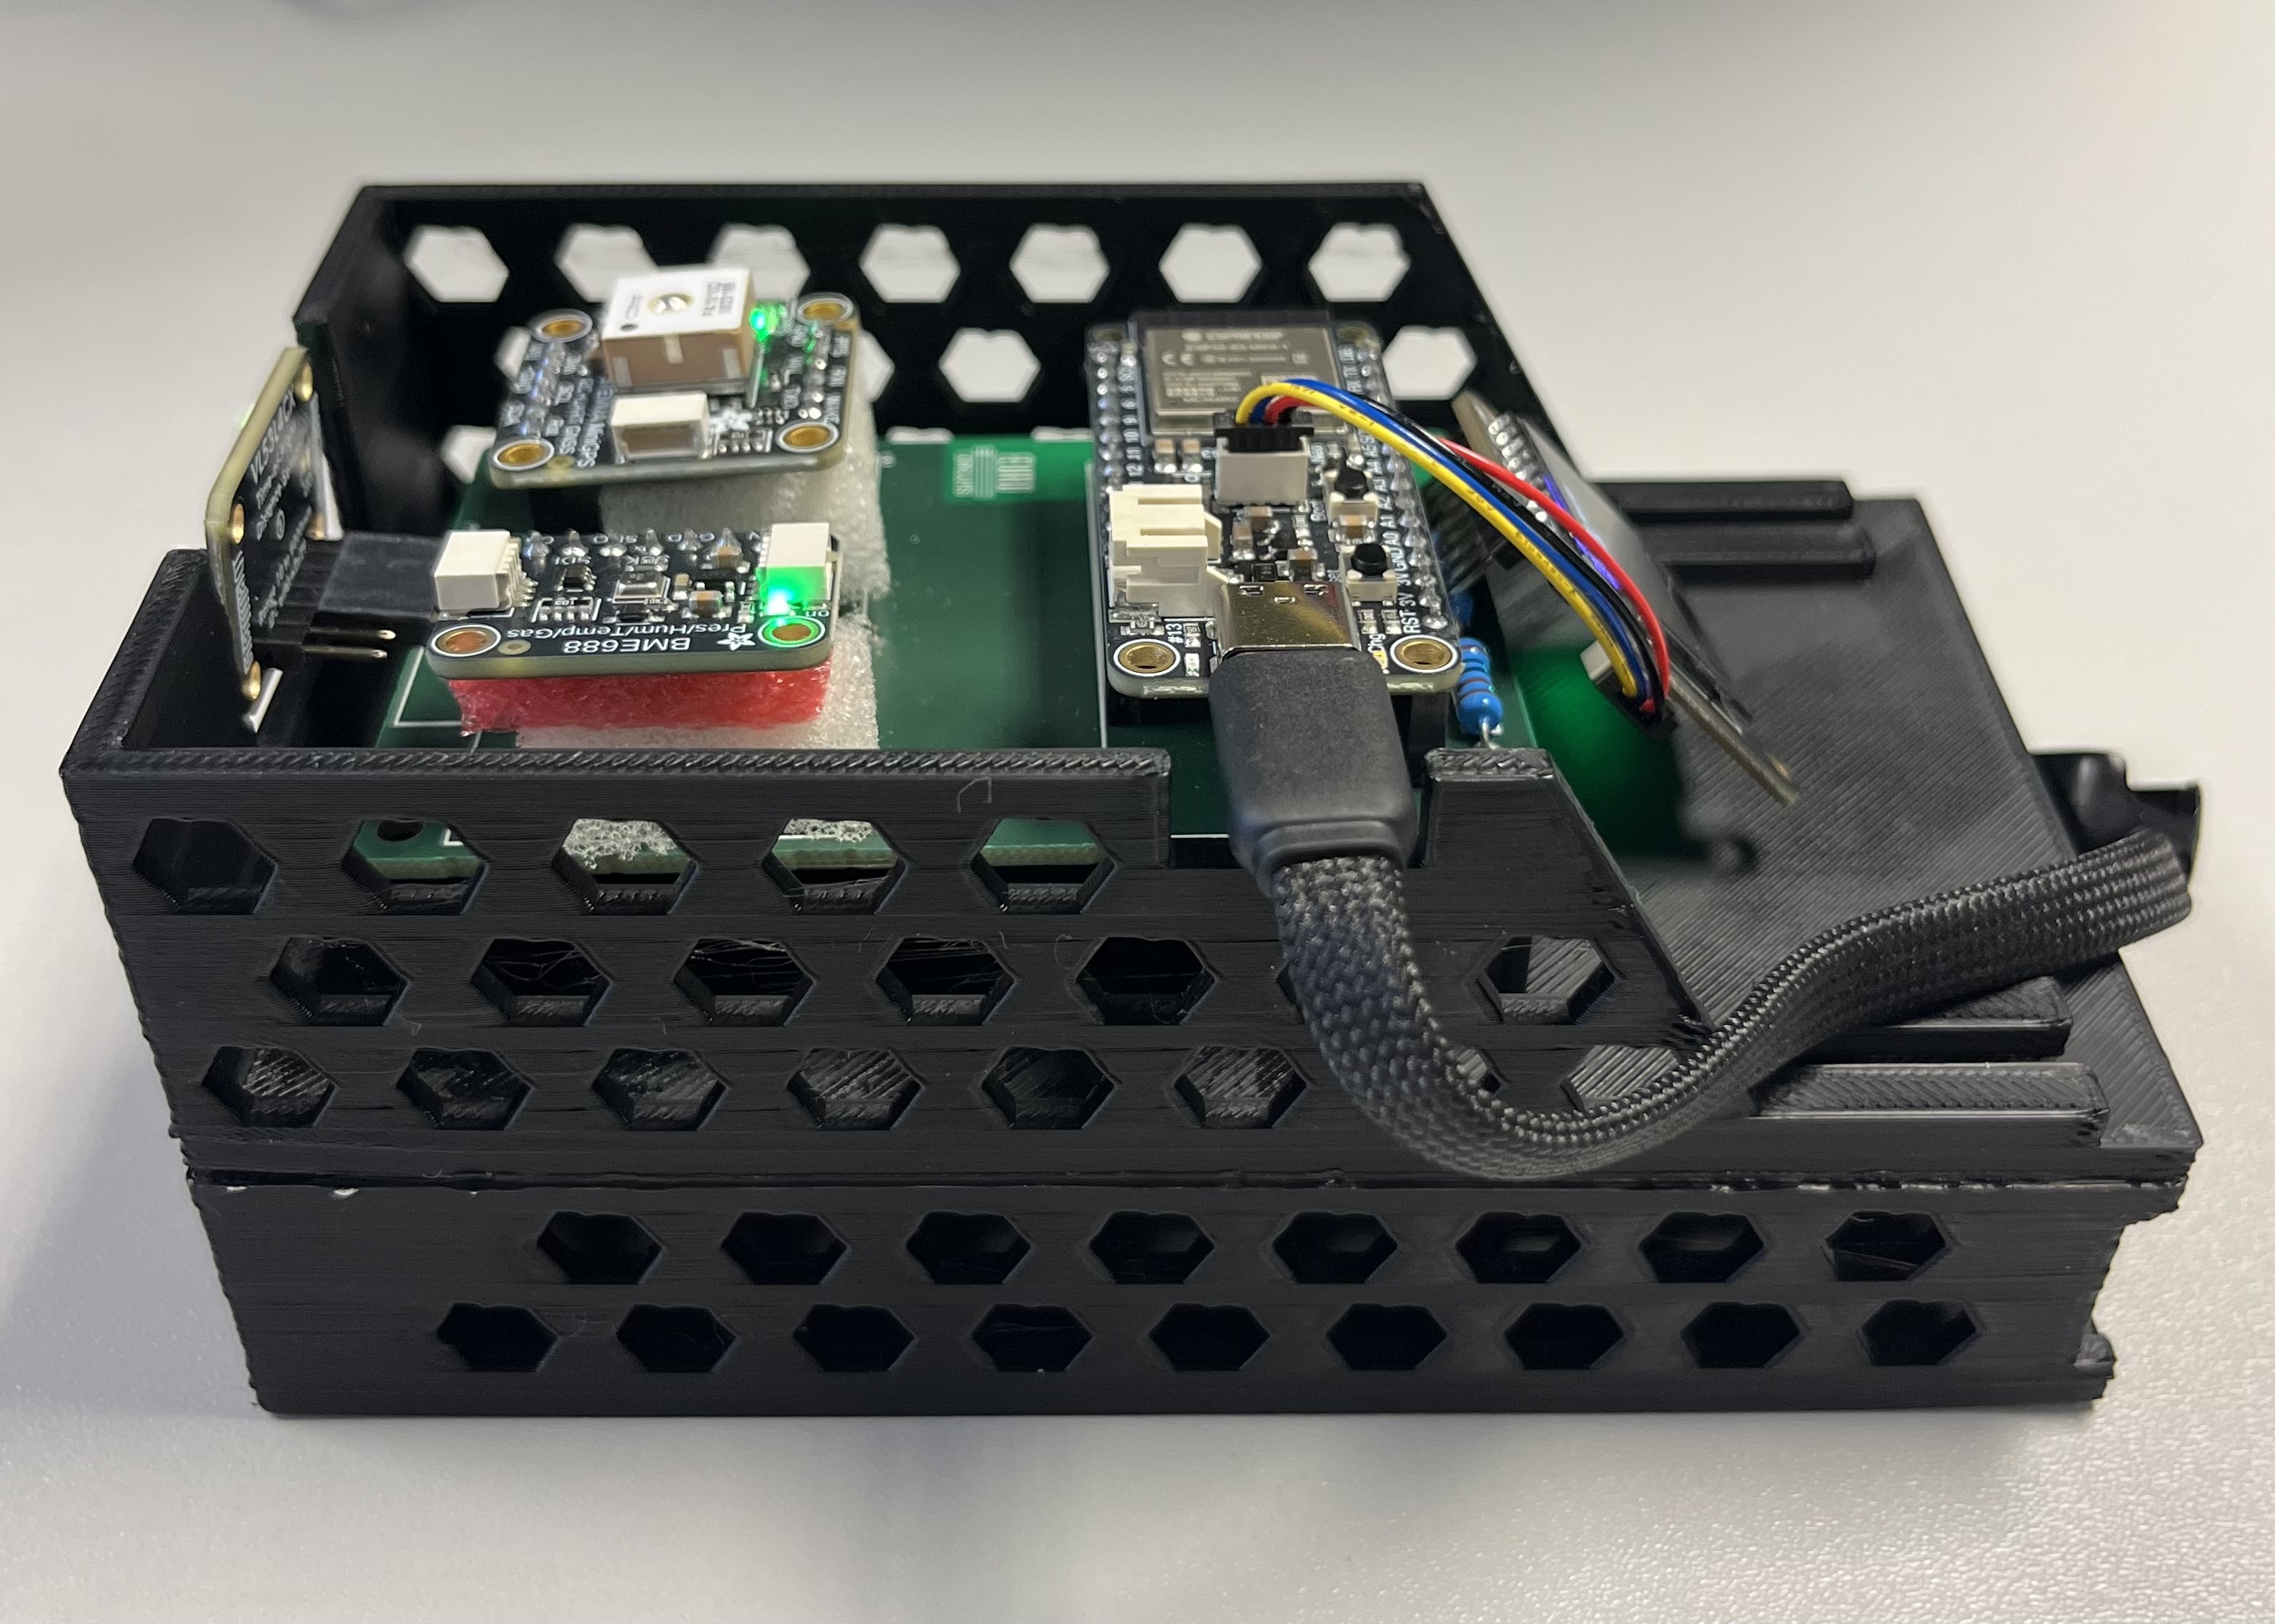
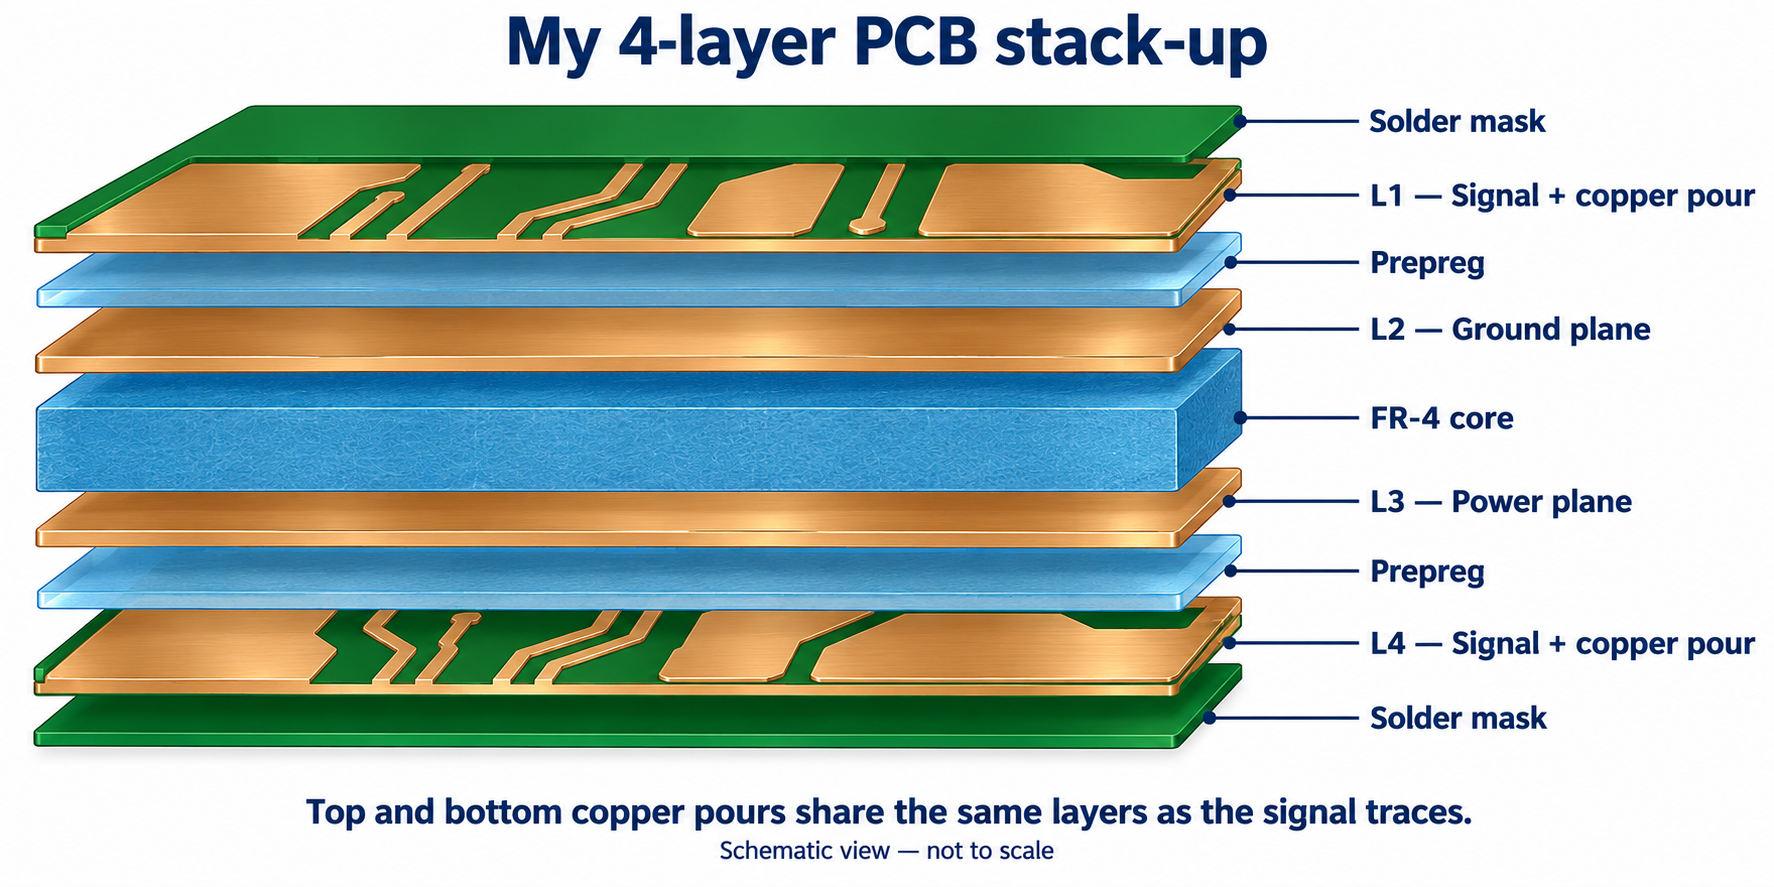
I designed wearable MAX30102 PPG and LIS2DE12 motion-sensing boards for patient-monitoring contexts, alongside an ESP32-S3 environmental hub. The room monitor combines temperature, humidity, pressure and gas sensing with an OLED, time-of-flight input and GPS integration. Its included firmware provides sensor acquisition, browser telemetry over server-sent events and HTTP upload. The wider system design connects wearable BLE data, local microSD logging and a receiving SQLite service. I also revised the PPG board placement, antenna clearance and four-layer layout.

Capabilities

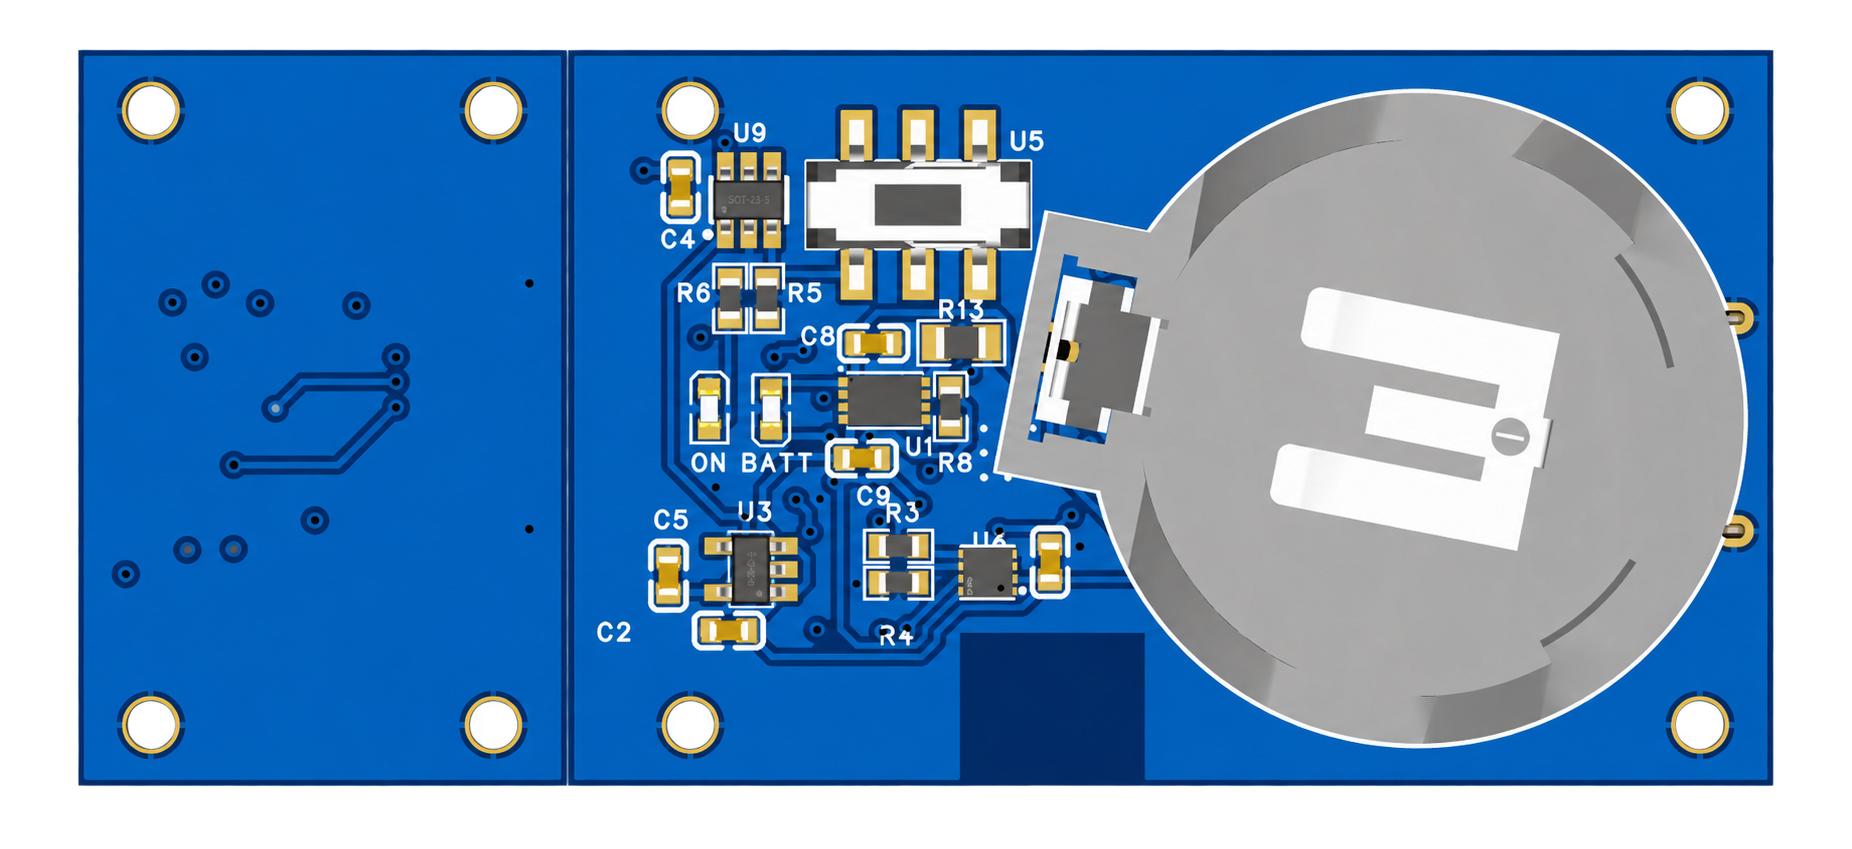
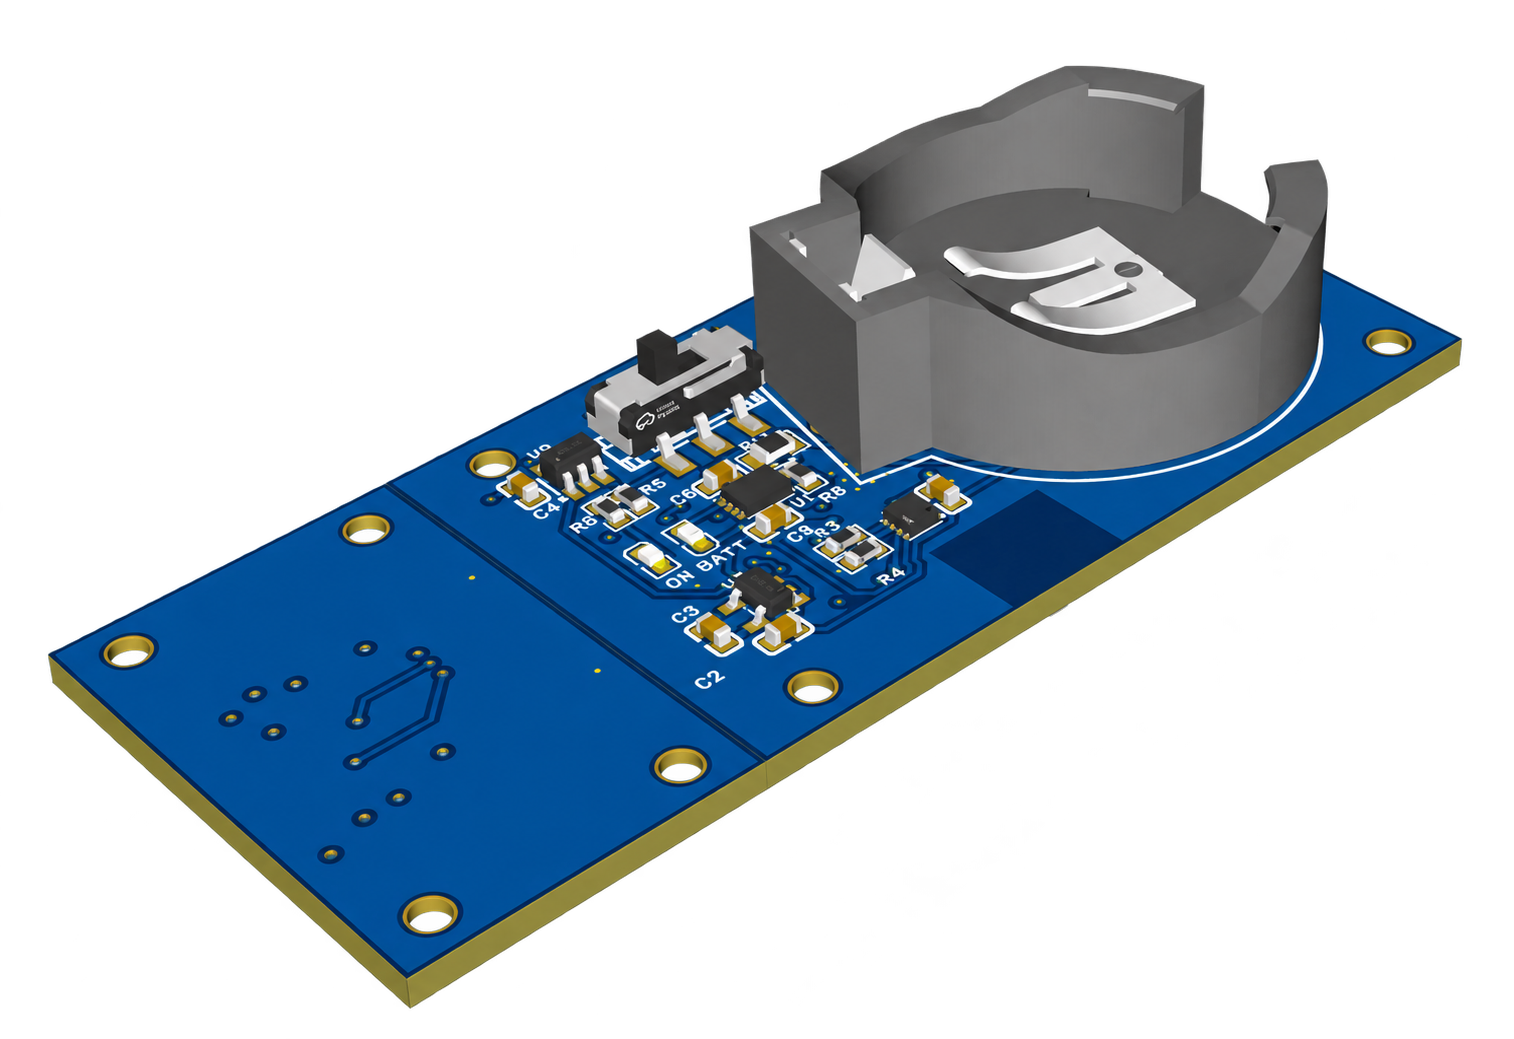
  • ESP32-C3 PPG and accelerometer board design with battery management
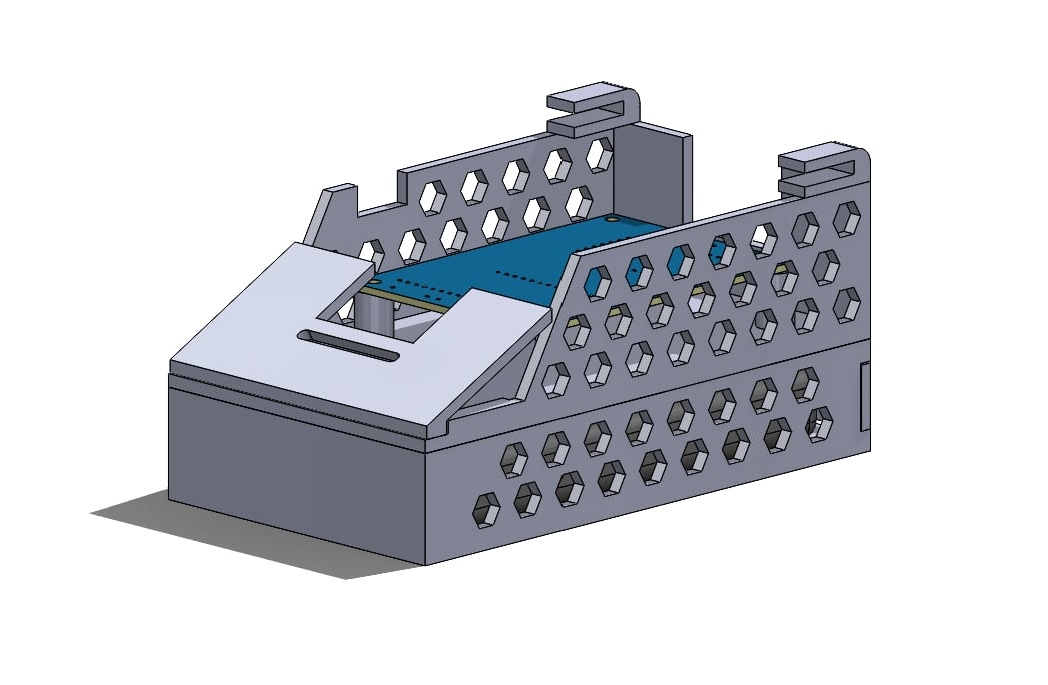
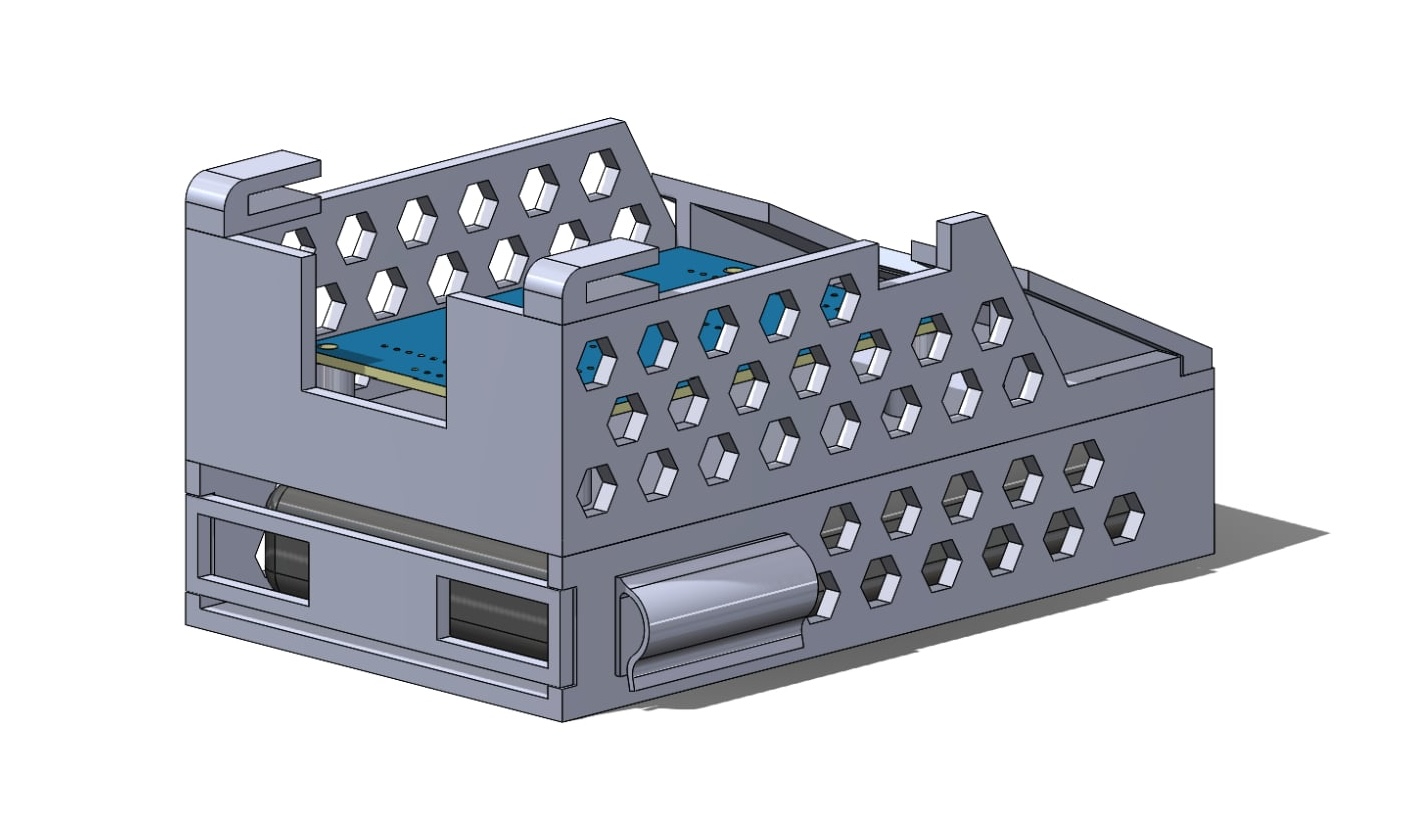
  • ESP32-S3 environmental sensing, OLED and a printed enclosure
  • Sensor acquisition, browser telemetry and HTTP upload firmware
  • Revised PPG PCB placement, antenna clearance and four-layer stack-up
PPG sensor PCB design view with components and board dimensionsPPG sensor PCB
Accelerometer PCB design view with components, battery holder and board dimensionsAccelerometer PCB
Environmental sensor electronics mounted inside the 3D-printed enclosureEnvironmental monitor
PPG and accelerometer PCB designs with the assembled environmental monitor.

Temperature sensors

Four sensors, one characterisation and datasheet workflow

I built the test electronics, STM32 acquisition and MATLAB analysis workflow to characterise four temperature sensors and develop individual sensor datasheets.

View project repository
What I built

Sensor characterisation and readout design

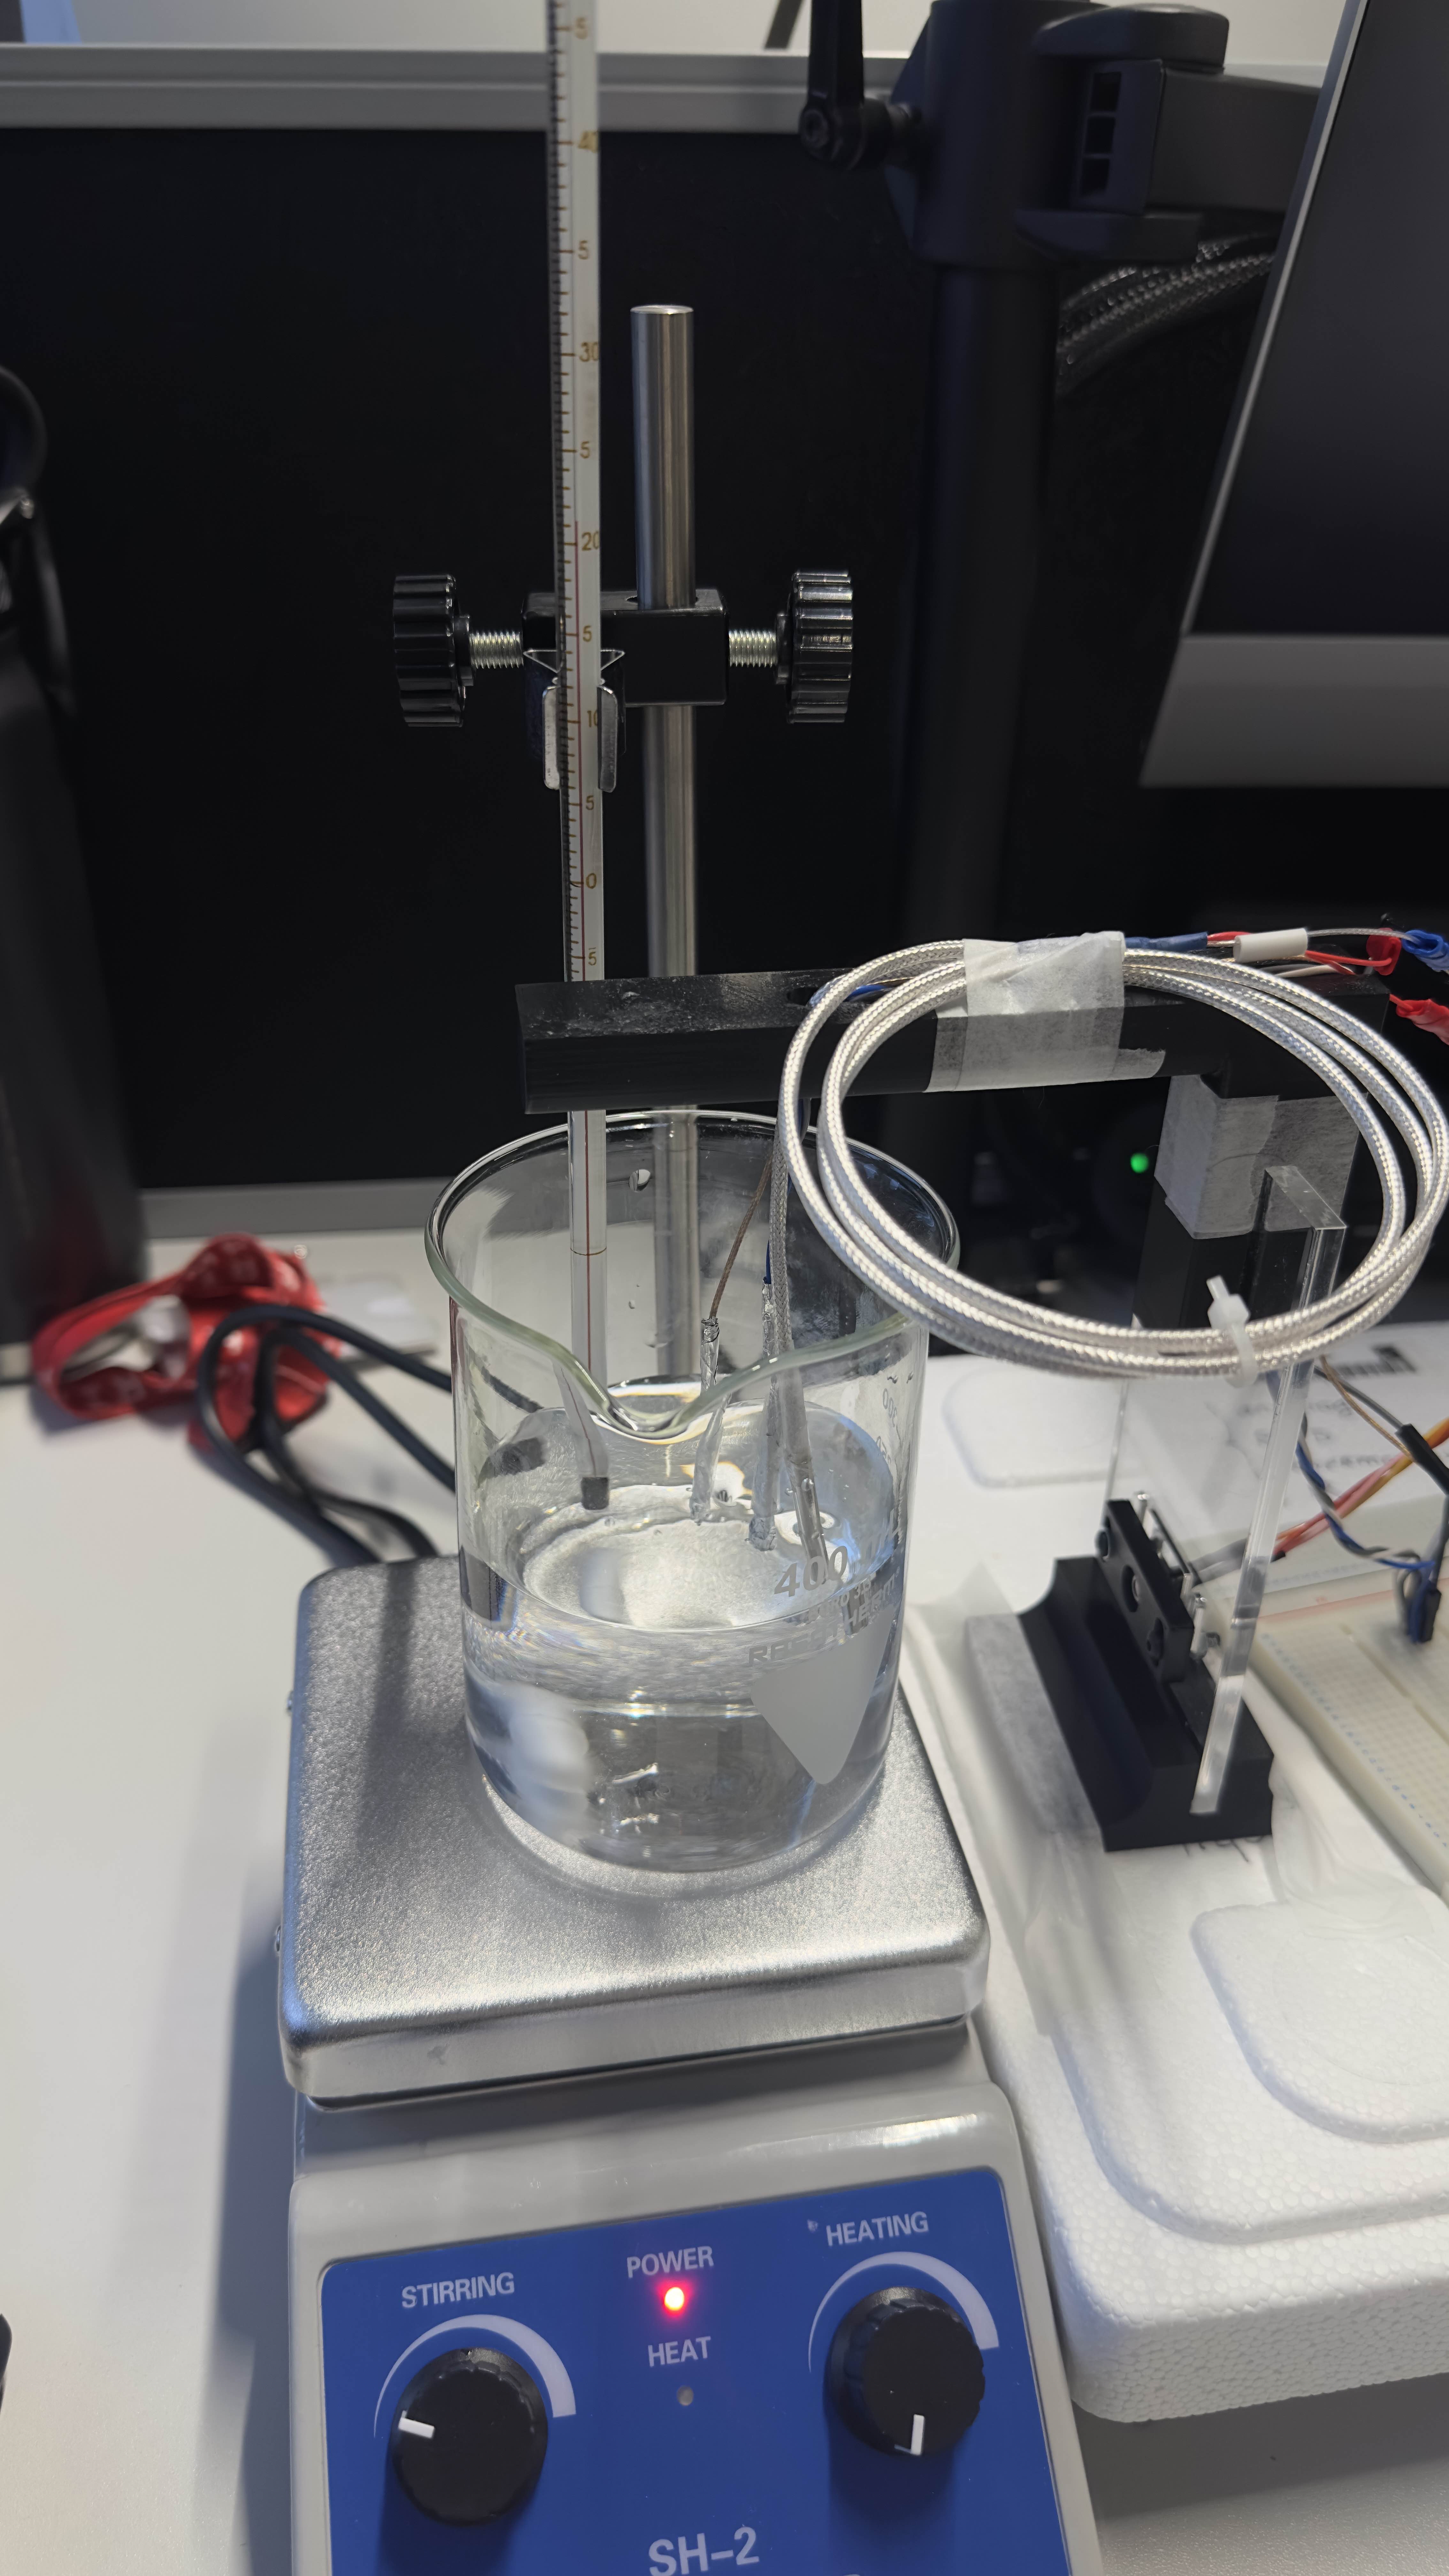
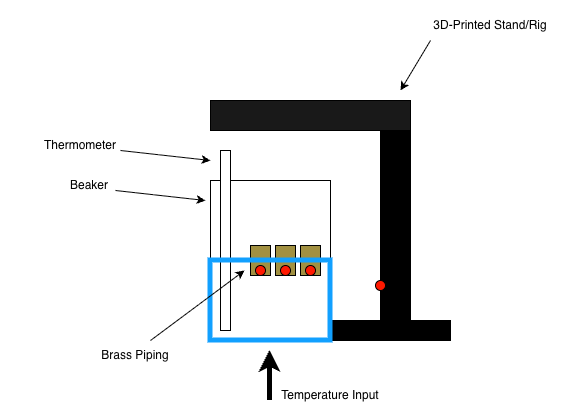
The goal was to characterise TMP36, PT1000, MLX90614 and MAX31855 sensors and turn their measured behaviour into individual sensor datasheets. I developed the readout electronics, experimental setup, STM32 acquisition and MATLAB logging and analysis. ADC, SPI and I2C readings stream over UART for comparison of sensitivity, linearity, accuracy and stability.

Capabilities

  • TMP36, PT1000, MLX90614 and MAX31855 characterisation
  • STM32 ADC, SPI, I2C and UART acquisition
  • MATLAB analysis for sensor comparison and datasheet preparation
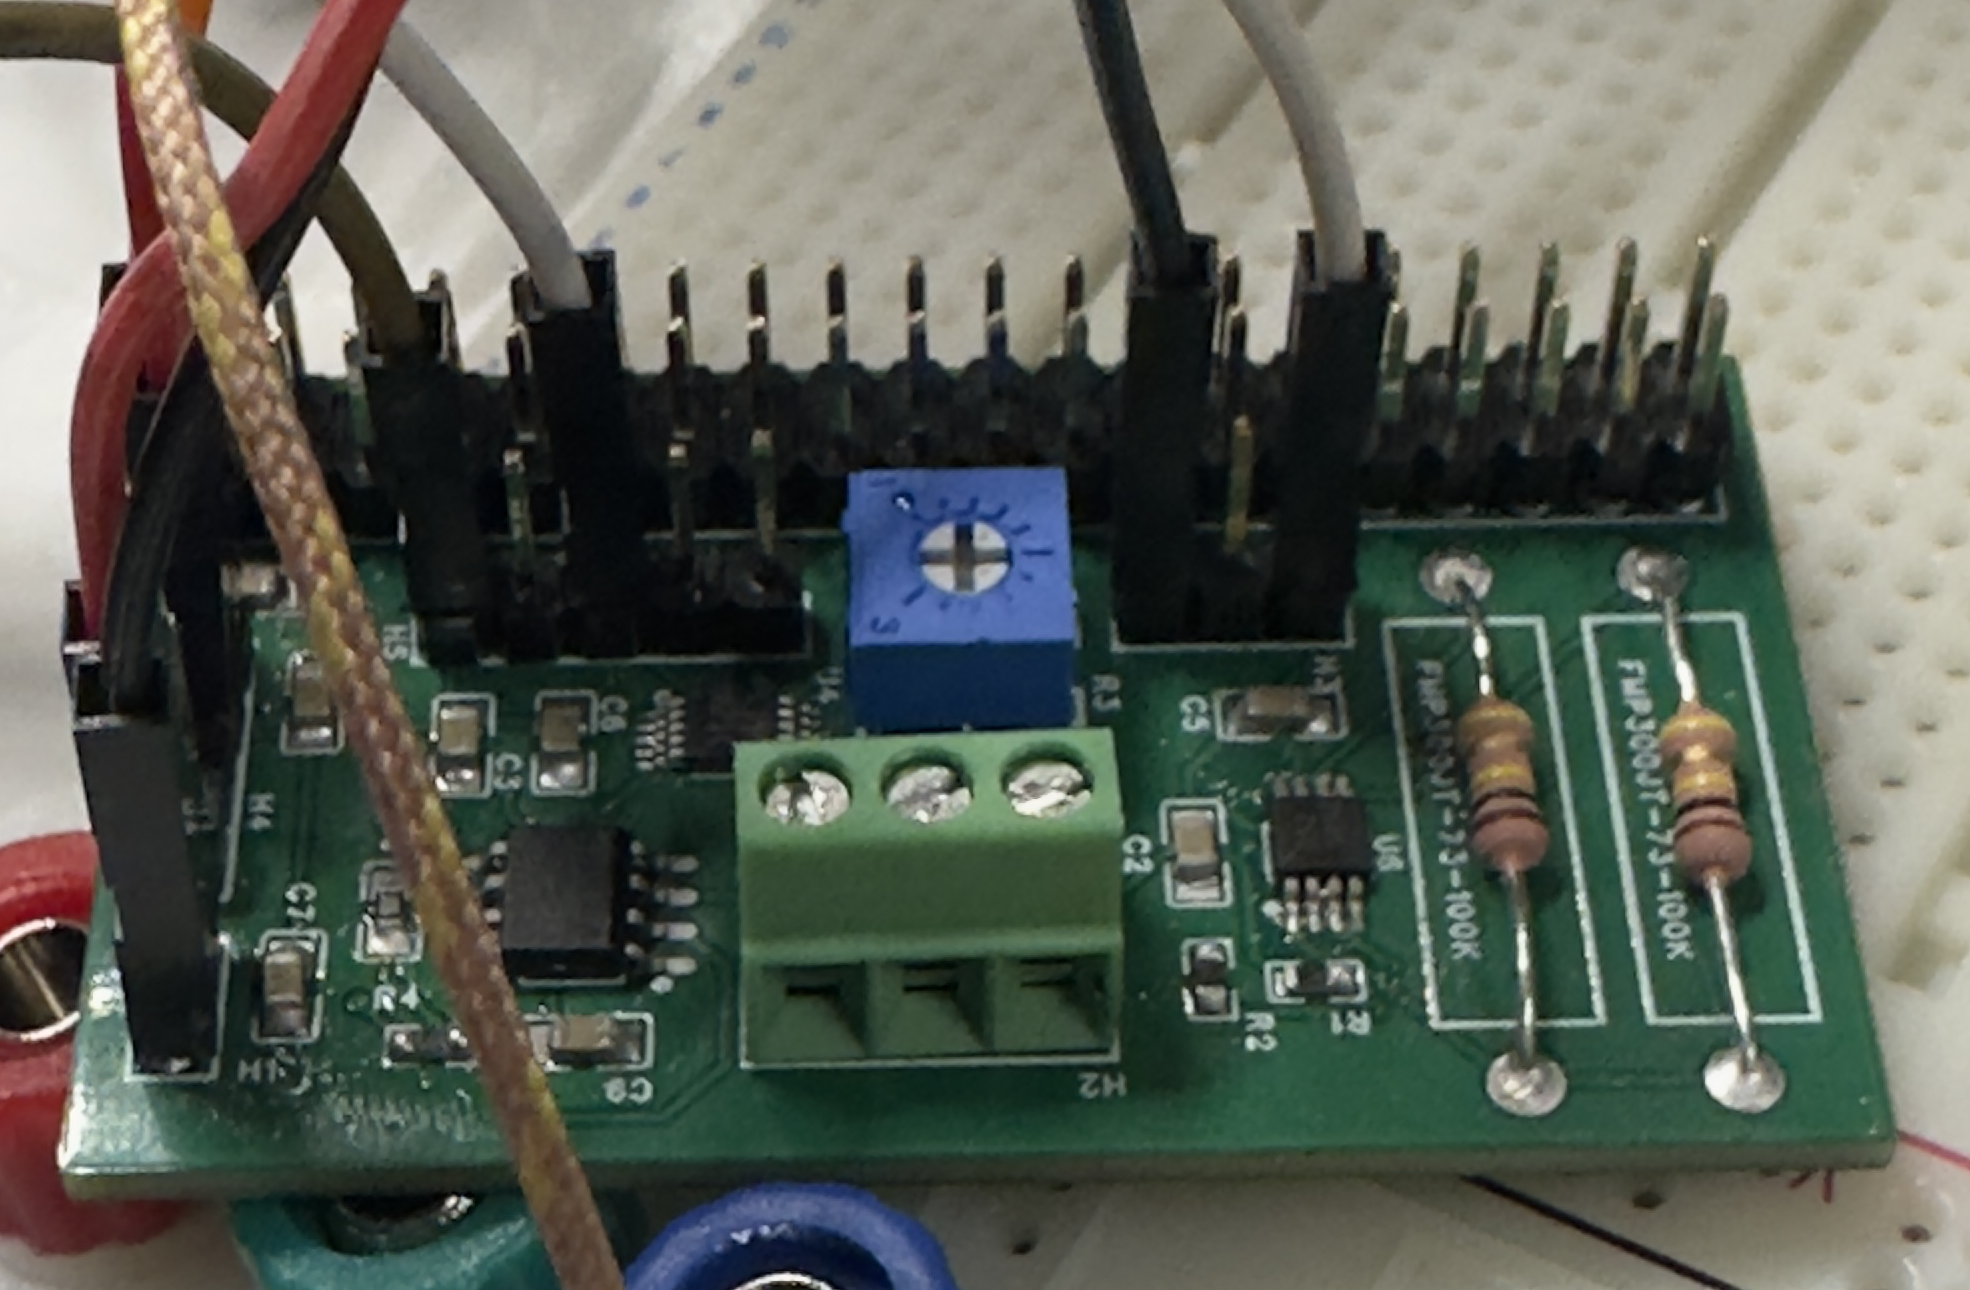
Original temperature-sensor readout PCB with headers, readout electronics and calibration trimmer
Temperature-sensor readout PCB and calibration electronics.

MEMS suspension solver

MATLAB finite-element beam analysis and interactive GUI

I implemented a MATLAB stiffness solver and GUI to analyse MEMS beam suspensions under loads, constraints and prescribed displacements.

GitHub · private
What I built

Beam solver and interactive MATLAB interface

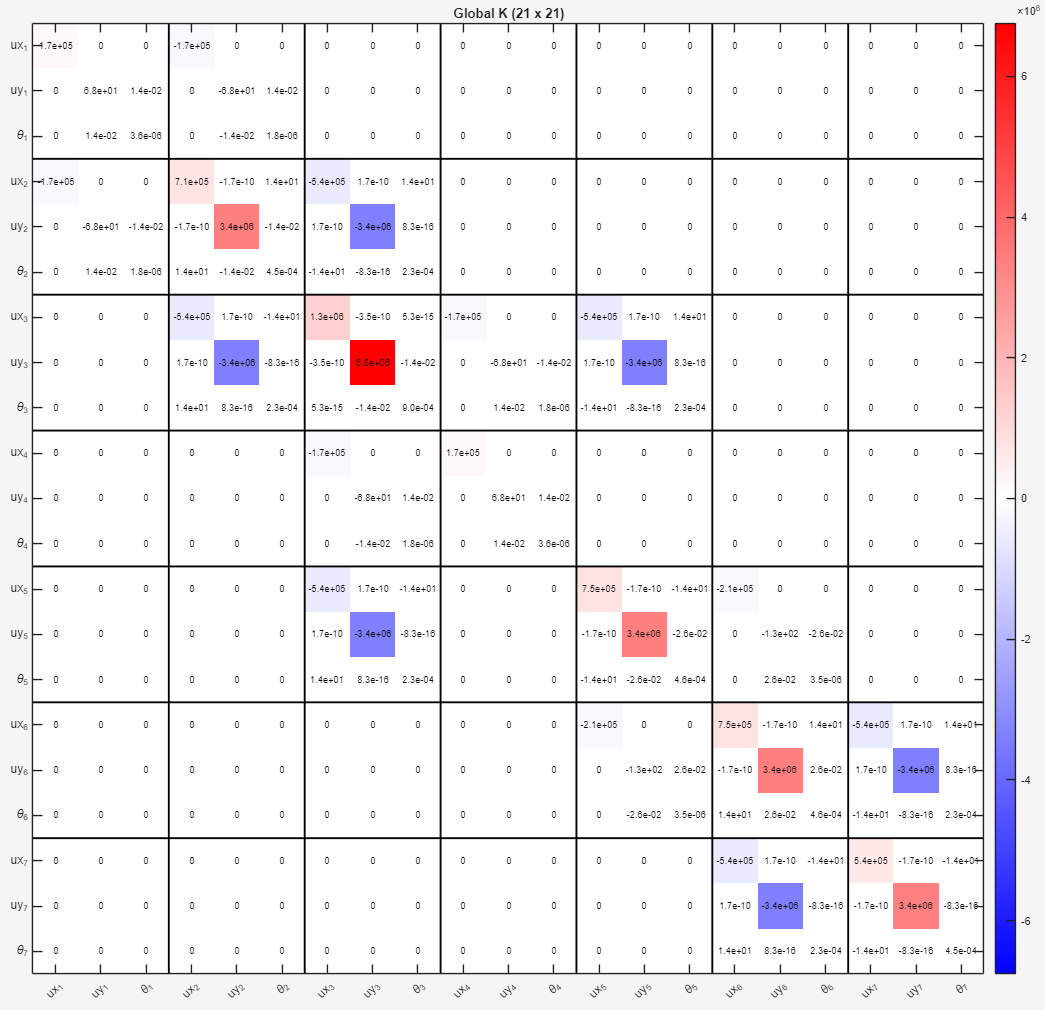
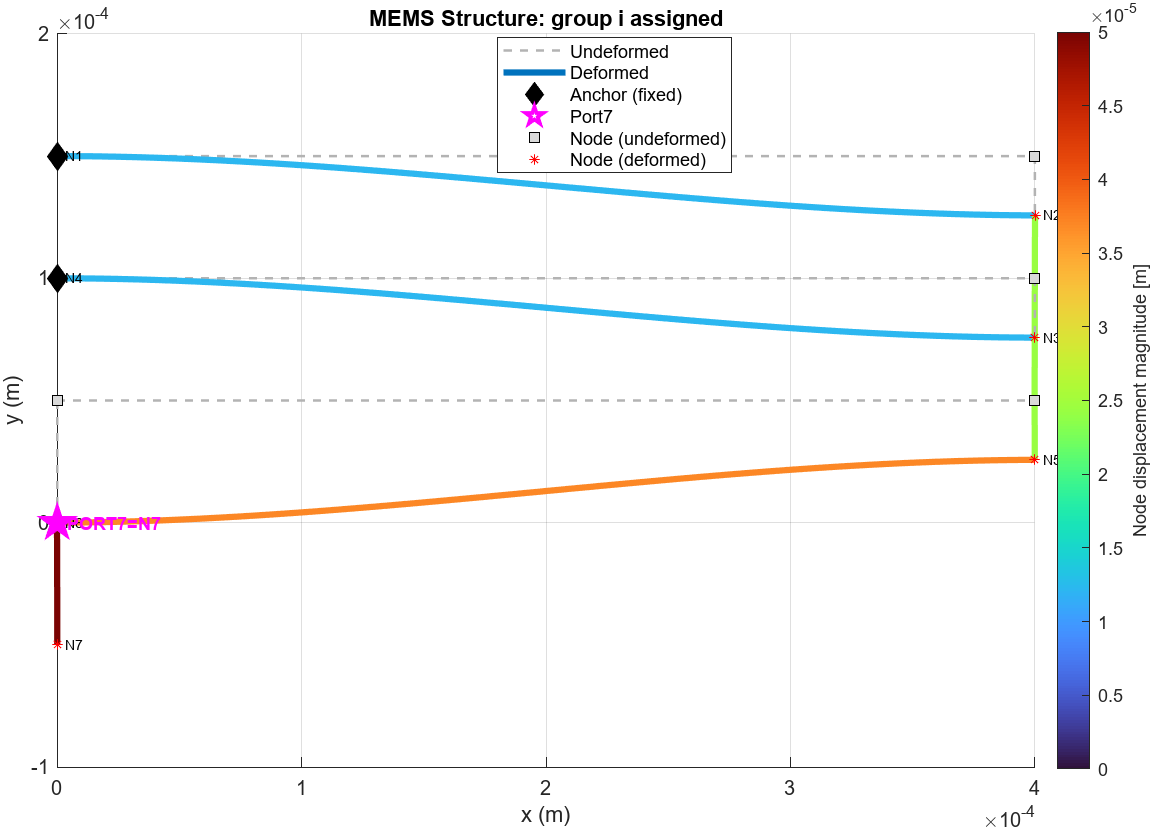
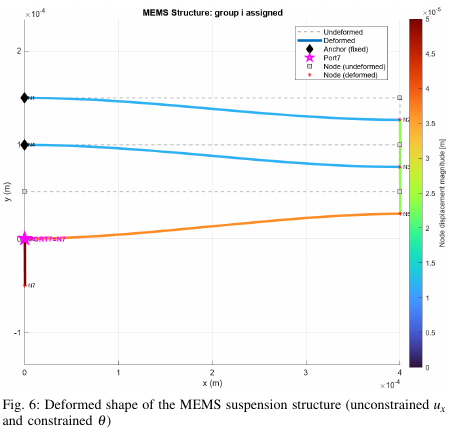
I developed a planar Euler–Bernoulli beam solver with three degrees of freedom per node. It assembles the global stiffness matrix, applies constraints and prescribed displacements, and computes displacements and reaction forces. An interactive MATLAB GUI exposes geometry, material, load and constraint inputs alongside deformed-shape and matrix views. Analytical cantilever cases provide checks before analysing a multi-element suspension.

Capabilities

  • Global stiffness assembly for 2D beam networks
  • Boundary conditions, imposed motion and reaction forces
  • MATLAB GUI and deformed-shape visualisation
Colour-coded 21 by 21 global stiffness matrix with labelled degrees of freedom and a complete colour scale.
Global stiffness matrix assembled by the MATLAB suspension solver.

Flexible strain sensor

Microfabrication, bridge readout and deformation experiments

I fabricated a copper strain gauge on flexible polyimide and built a bridge-based analogue readout to investigate its response to deformation.

GitHub · private
What I built

My fabrication and readout work

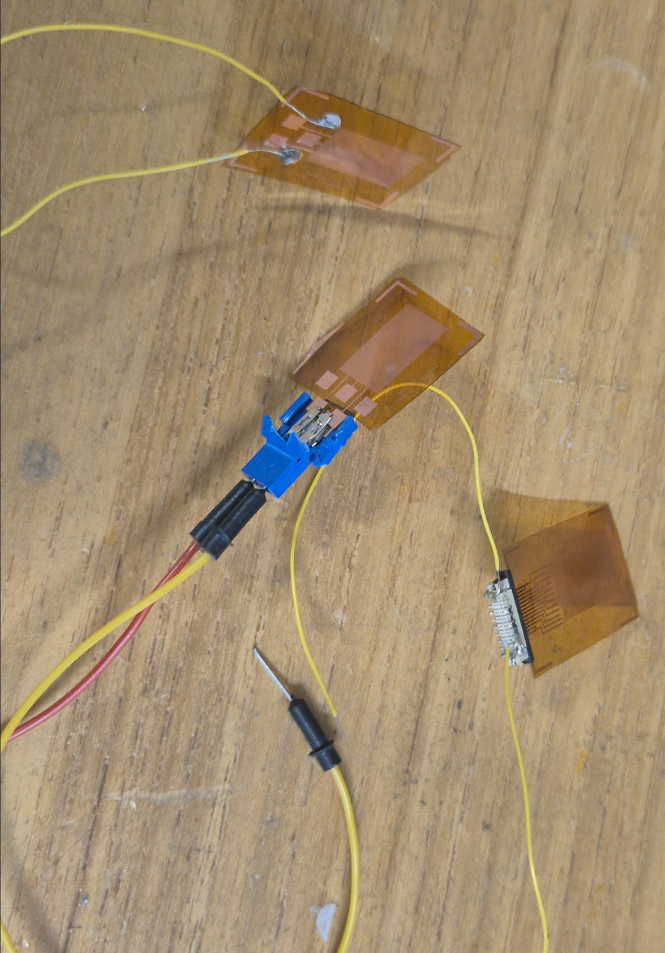
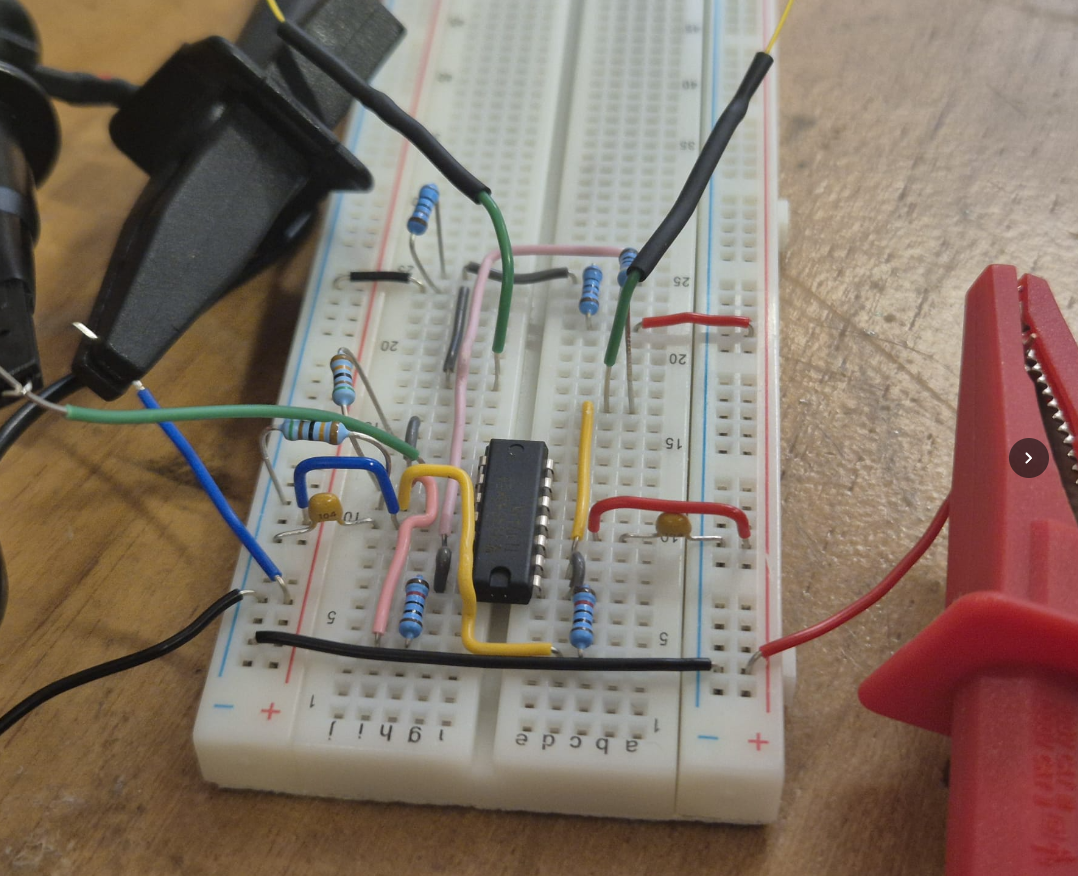
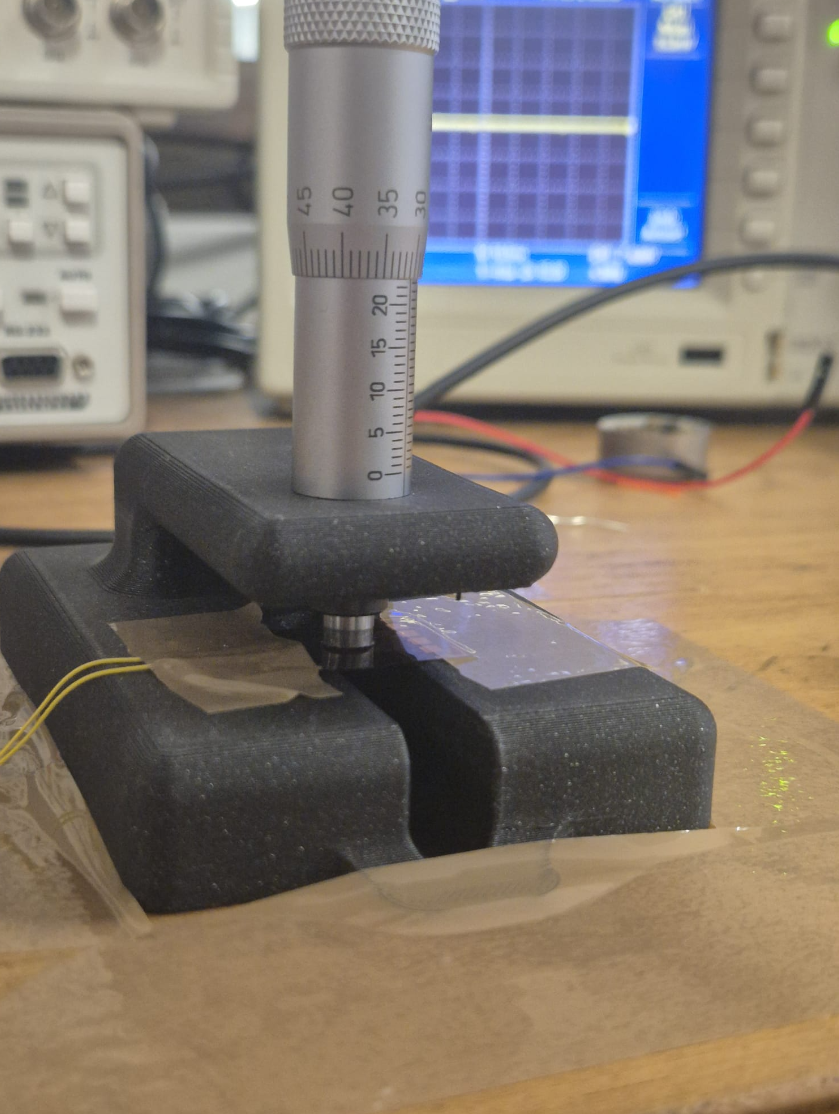
I used thin-film deposition, lithography and wet etching to form copper strain tracks on a flexible polyimide substrate. A Wheatstone bridge, buffers and amplifier provided the electrical readout. I investigated displacement and bending-angle tests, including a fixture for applying controlled deformation.

Capabilities

  • Copper-on-polyimide strain-gauge fabrication
  • Wheatstone bridge and analogue signal conditioning
  • Deformation fixtures and response characterisation
Three fabricated copper-on-polyimide flexible sensor samples with their original wires and connections
Fabricated copper-on-polyimide gauges and their electrical connections.

Sensor-controlled arm

EMG and pressure sensing for prosthetic control

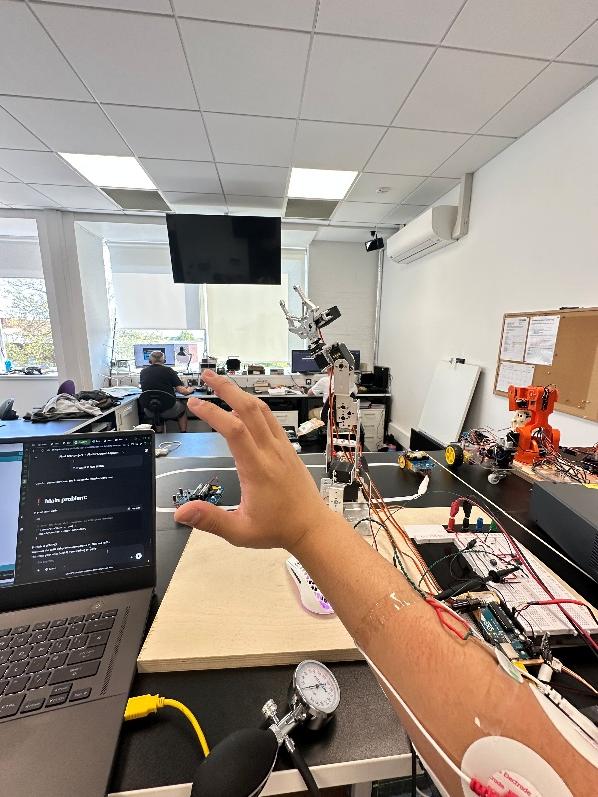
I built sensing circuits and Arduino control logic to turn EMG and pressure inputs into robotic arm and gripper actions.

GitHub · private
What I built

My sensing and integration work

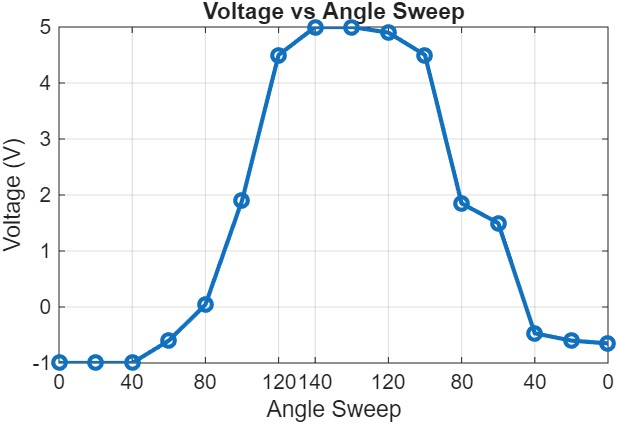
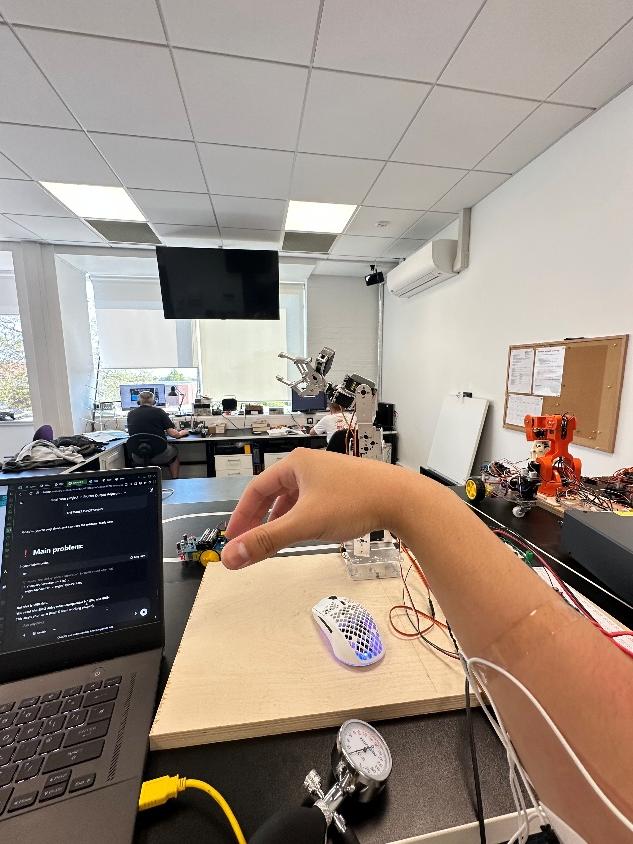
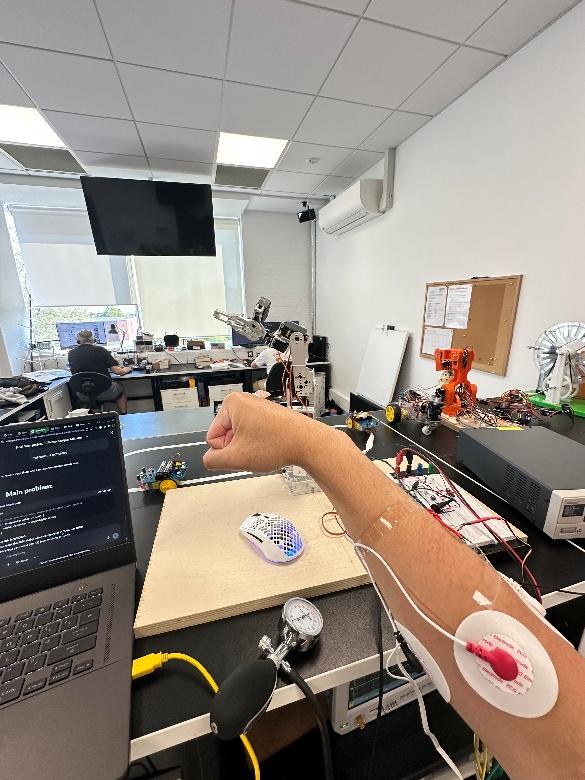
I investigated EMG, pressure and triboelectric sensing for a robotic arm and gripper. I developed analogue conditioning circuits and Arduino control logic, compared the sensor responses, and integrated EMG and pressure inputs. Threshold detection translated the readings into arm and gripping actions.

Capabilities

  • EMG and pressure input processing
  • Arduino arm and gripper control
  • Analogue conditioning and sensor comparison
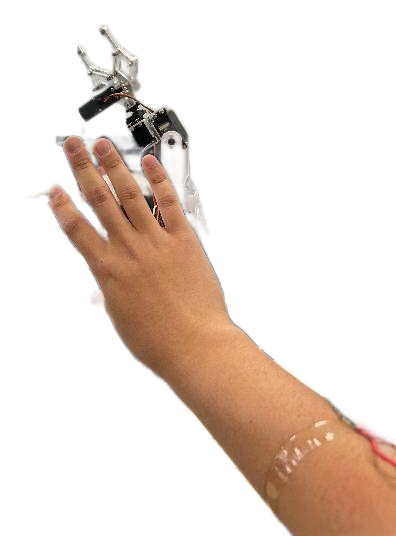
Forearm sensing connections and robotic gripper demonstrator isolated from its laboratory background
Hand, sensing connections and robotic gripper from the integrated demonstrator.

FPGA FIR filtering

Basys3 FIR configuration, converter measurements and Python analysis

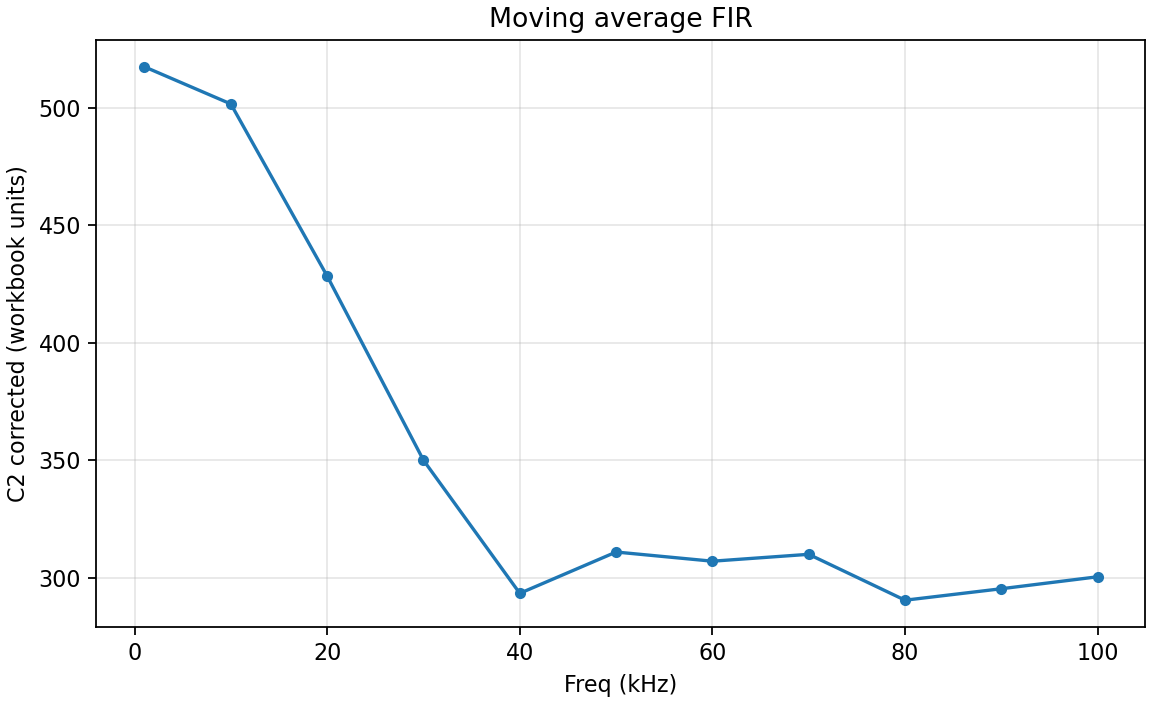
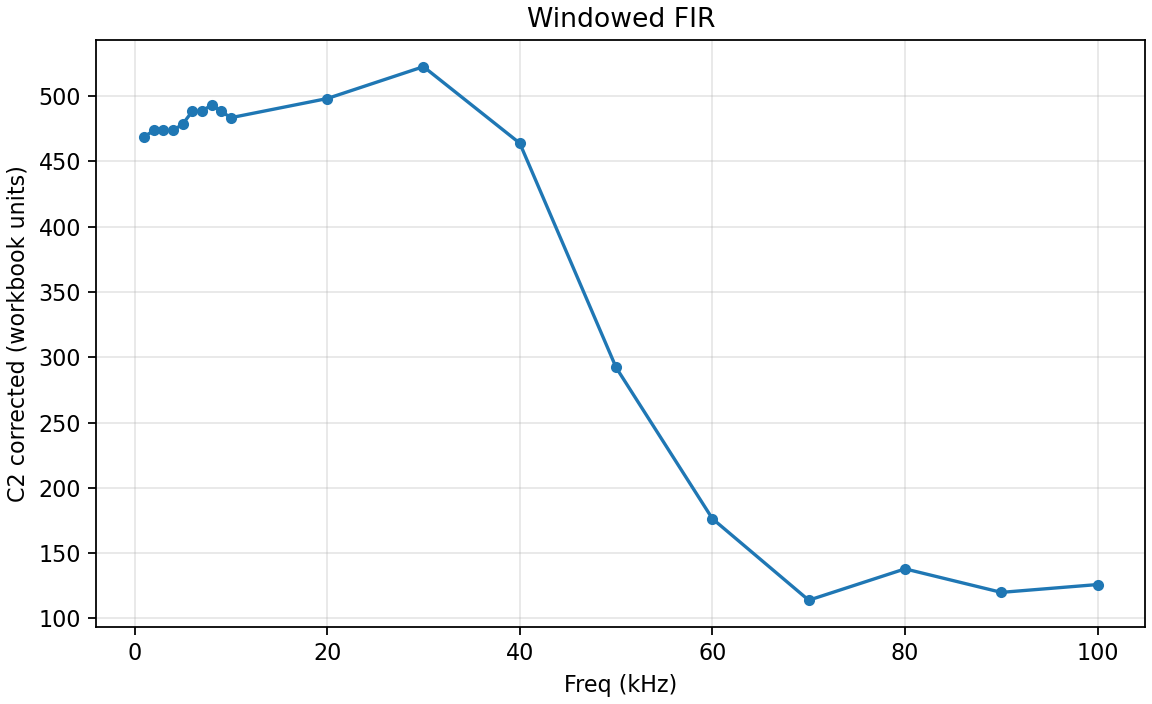
I configured FIR responses on a Basys3 and analysed the recorded ADC-to-DAC measurements with Python.

GitHub · private
What I built

FIR configuration and measurement analysis

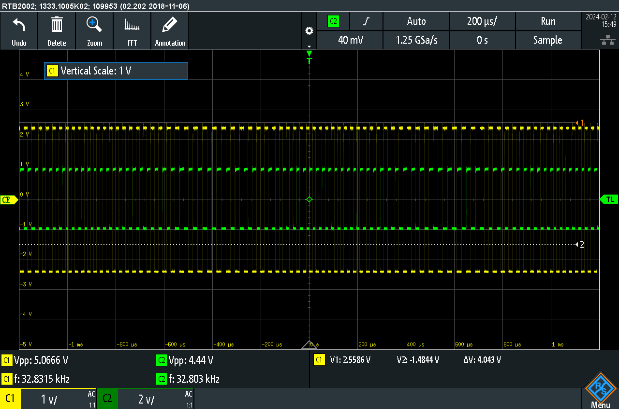
I configured pass-through, five-tap moving-average and seven-tap windowed FIR responses on a Basys3 using a supplied Verilog FIR framework. I connected the Pmod AD1 input and Pmod DA2 output, recorded oscilloscope measurements and developed Python tools to plot the complete workbook response summaries and scope captures.

Capabilities

  • Signed FIR coefficient configuration in a supplied Verilog design
  • Pmod AD1, Basys3 and Pmod DA2 measurement chain
  • Python plotting for complete response summaries and scope captures
FPGA FIR filtering and response analysis.
Robotics and software
ROS 2, Python, C, RGB-D perception, Hand–eye calibration
Embedded and electronics
STM32, Sensor integration, PCB design, Verilog, UART, SPI and I2C
Design and analysis
MATLAB/Simulink, SolidWorks, Experimental data analysis

Background

Electronic Engineering graduate with an MSc in Sensor Systems Engineering.

Education

MSc Sensor Systems Engineering, Merit
Imperial College LondonSep 2025 to Sep 2026
Imperial College London degree certificate (1 page)
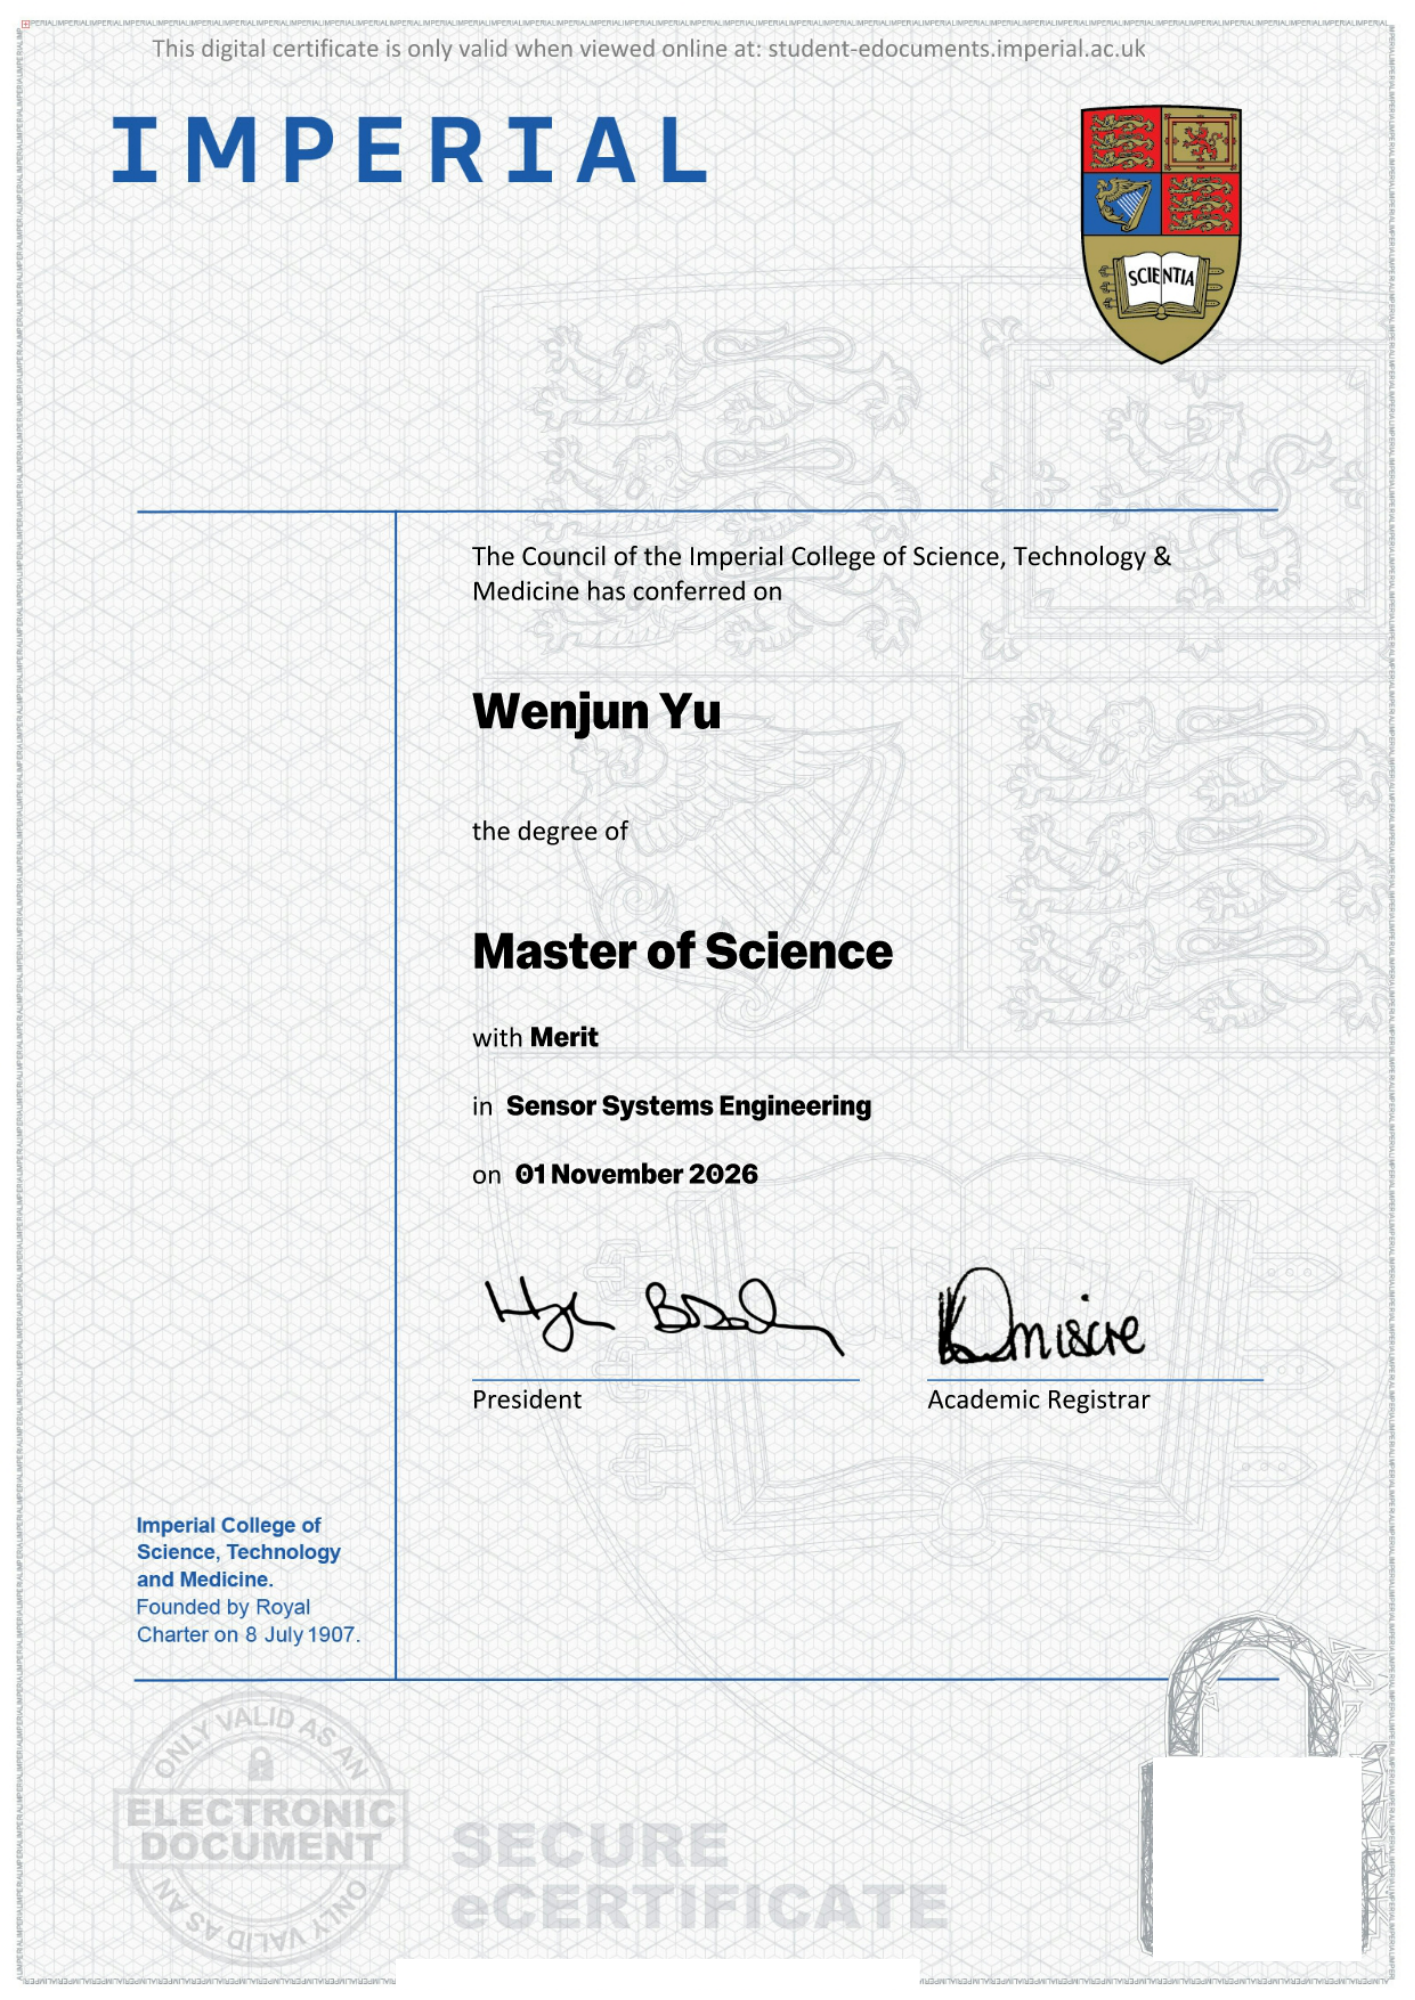
Open PDF: Imperial College London degree certificate
Imperial College London degree certificate, page 1; personal identifiers and verification codes removed where present.
Page 1

Personal identifiers hidden in displayed copies.

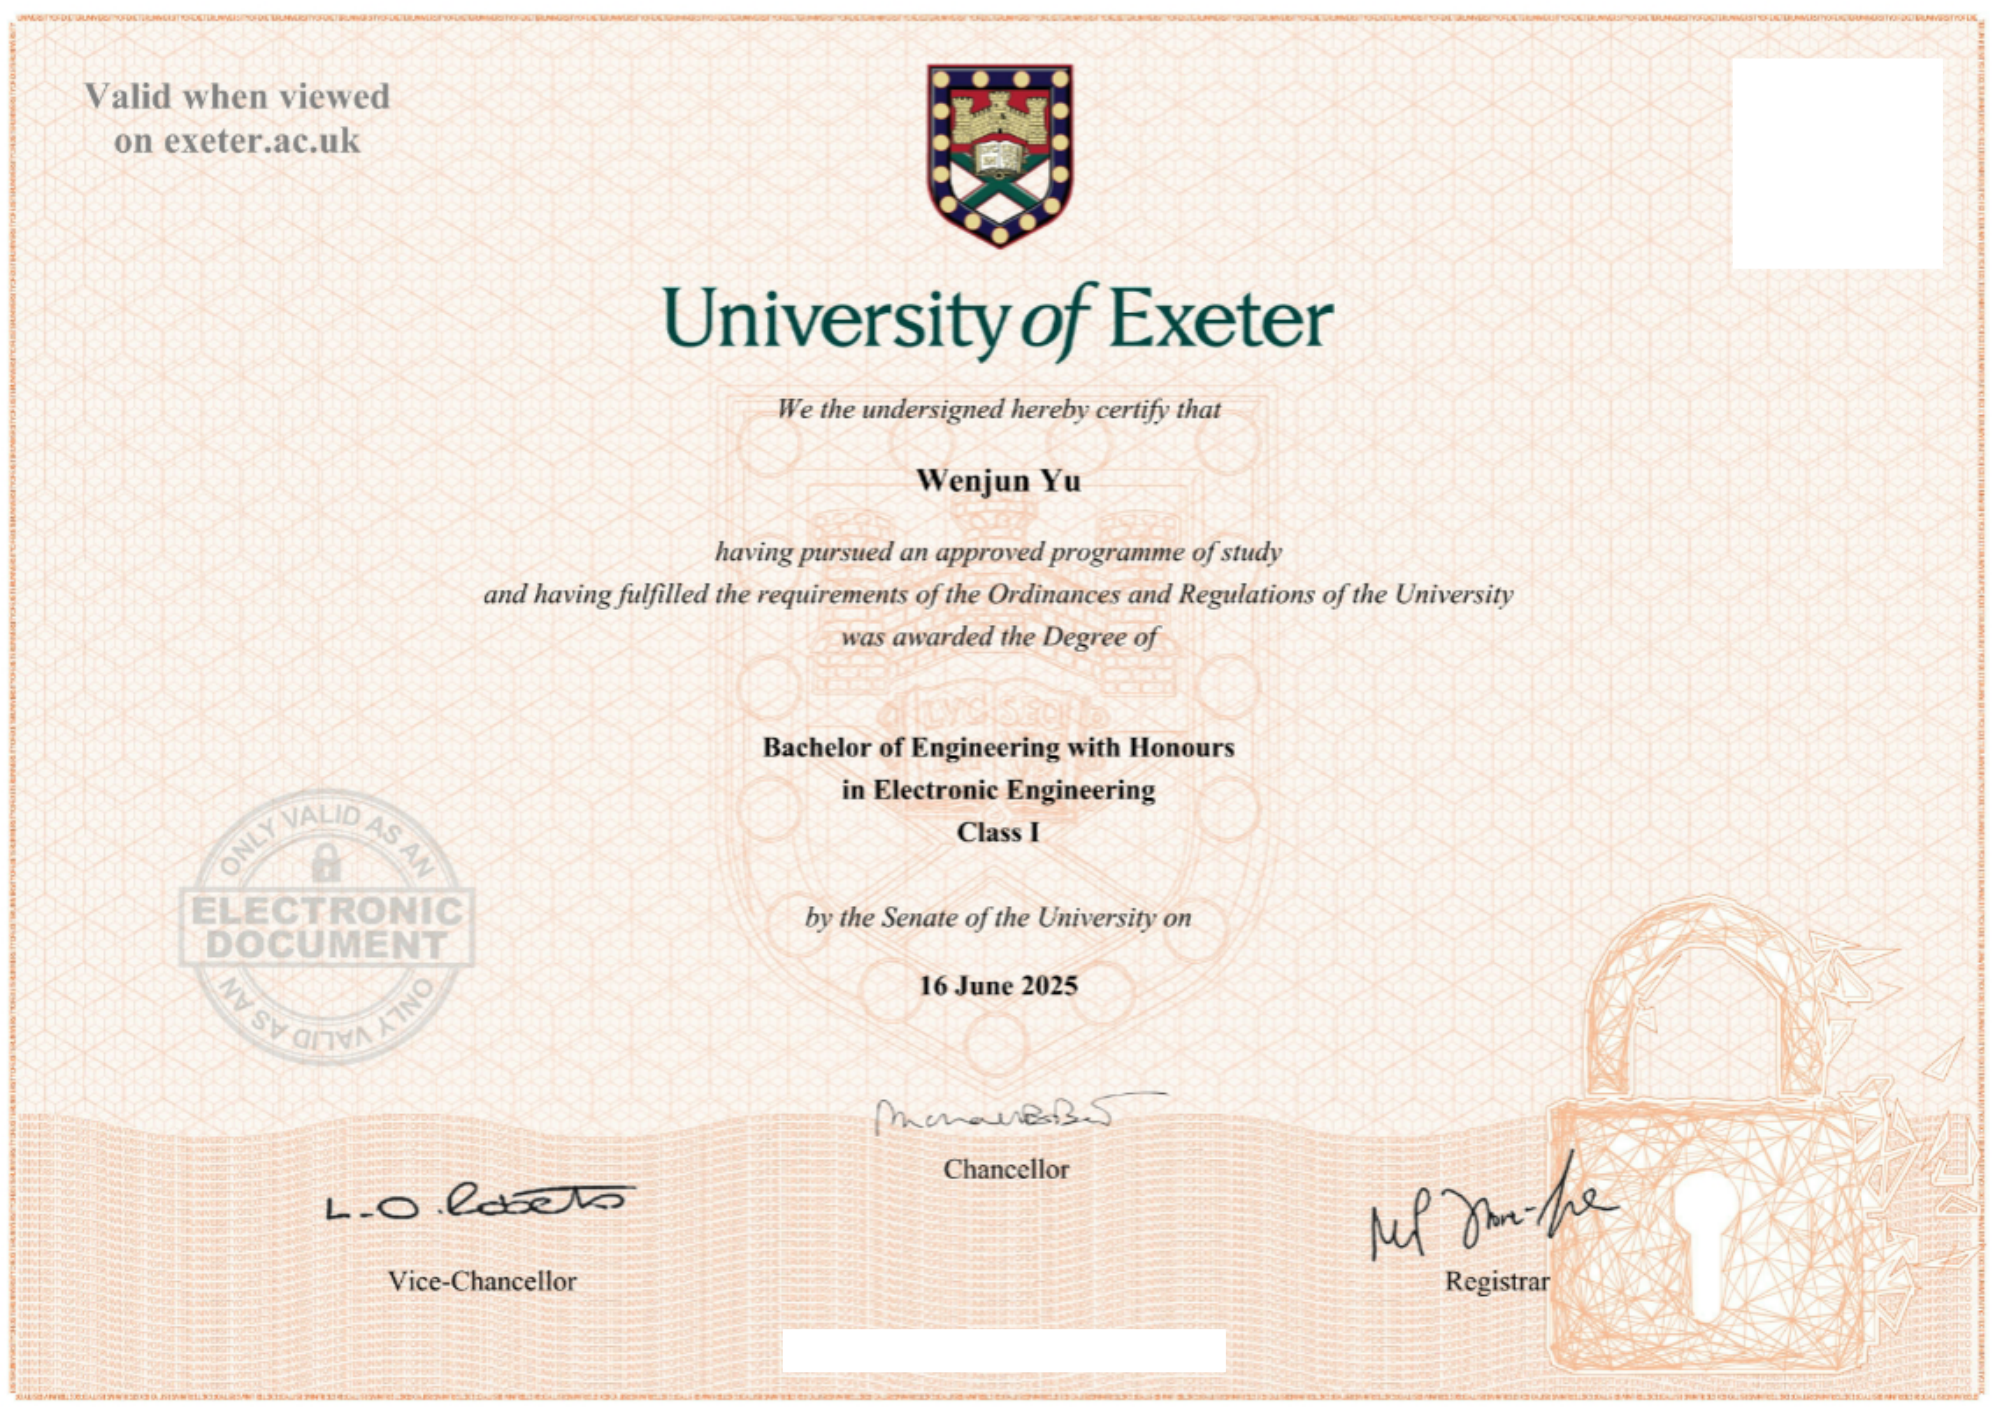
BEng Electronic Engineering, First Class Honours
University of ExeterSep 2022 to Jun 2025
University of Exeter degree certificate (1 page)
Open PDF: University of Exeter degree certificate
University of Exeter degree certificate, page 1; personal identifiers and verification codes removed where present.
Page 1

Personal identifiers hidden in displayed copies.

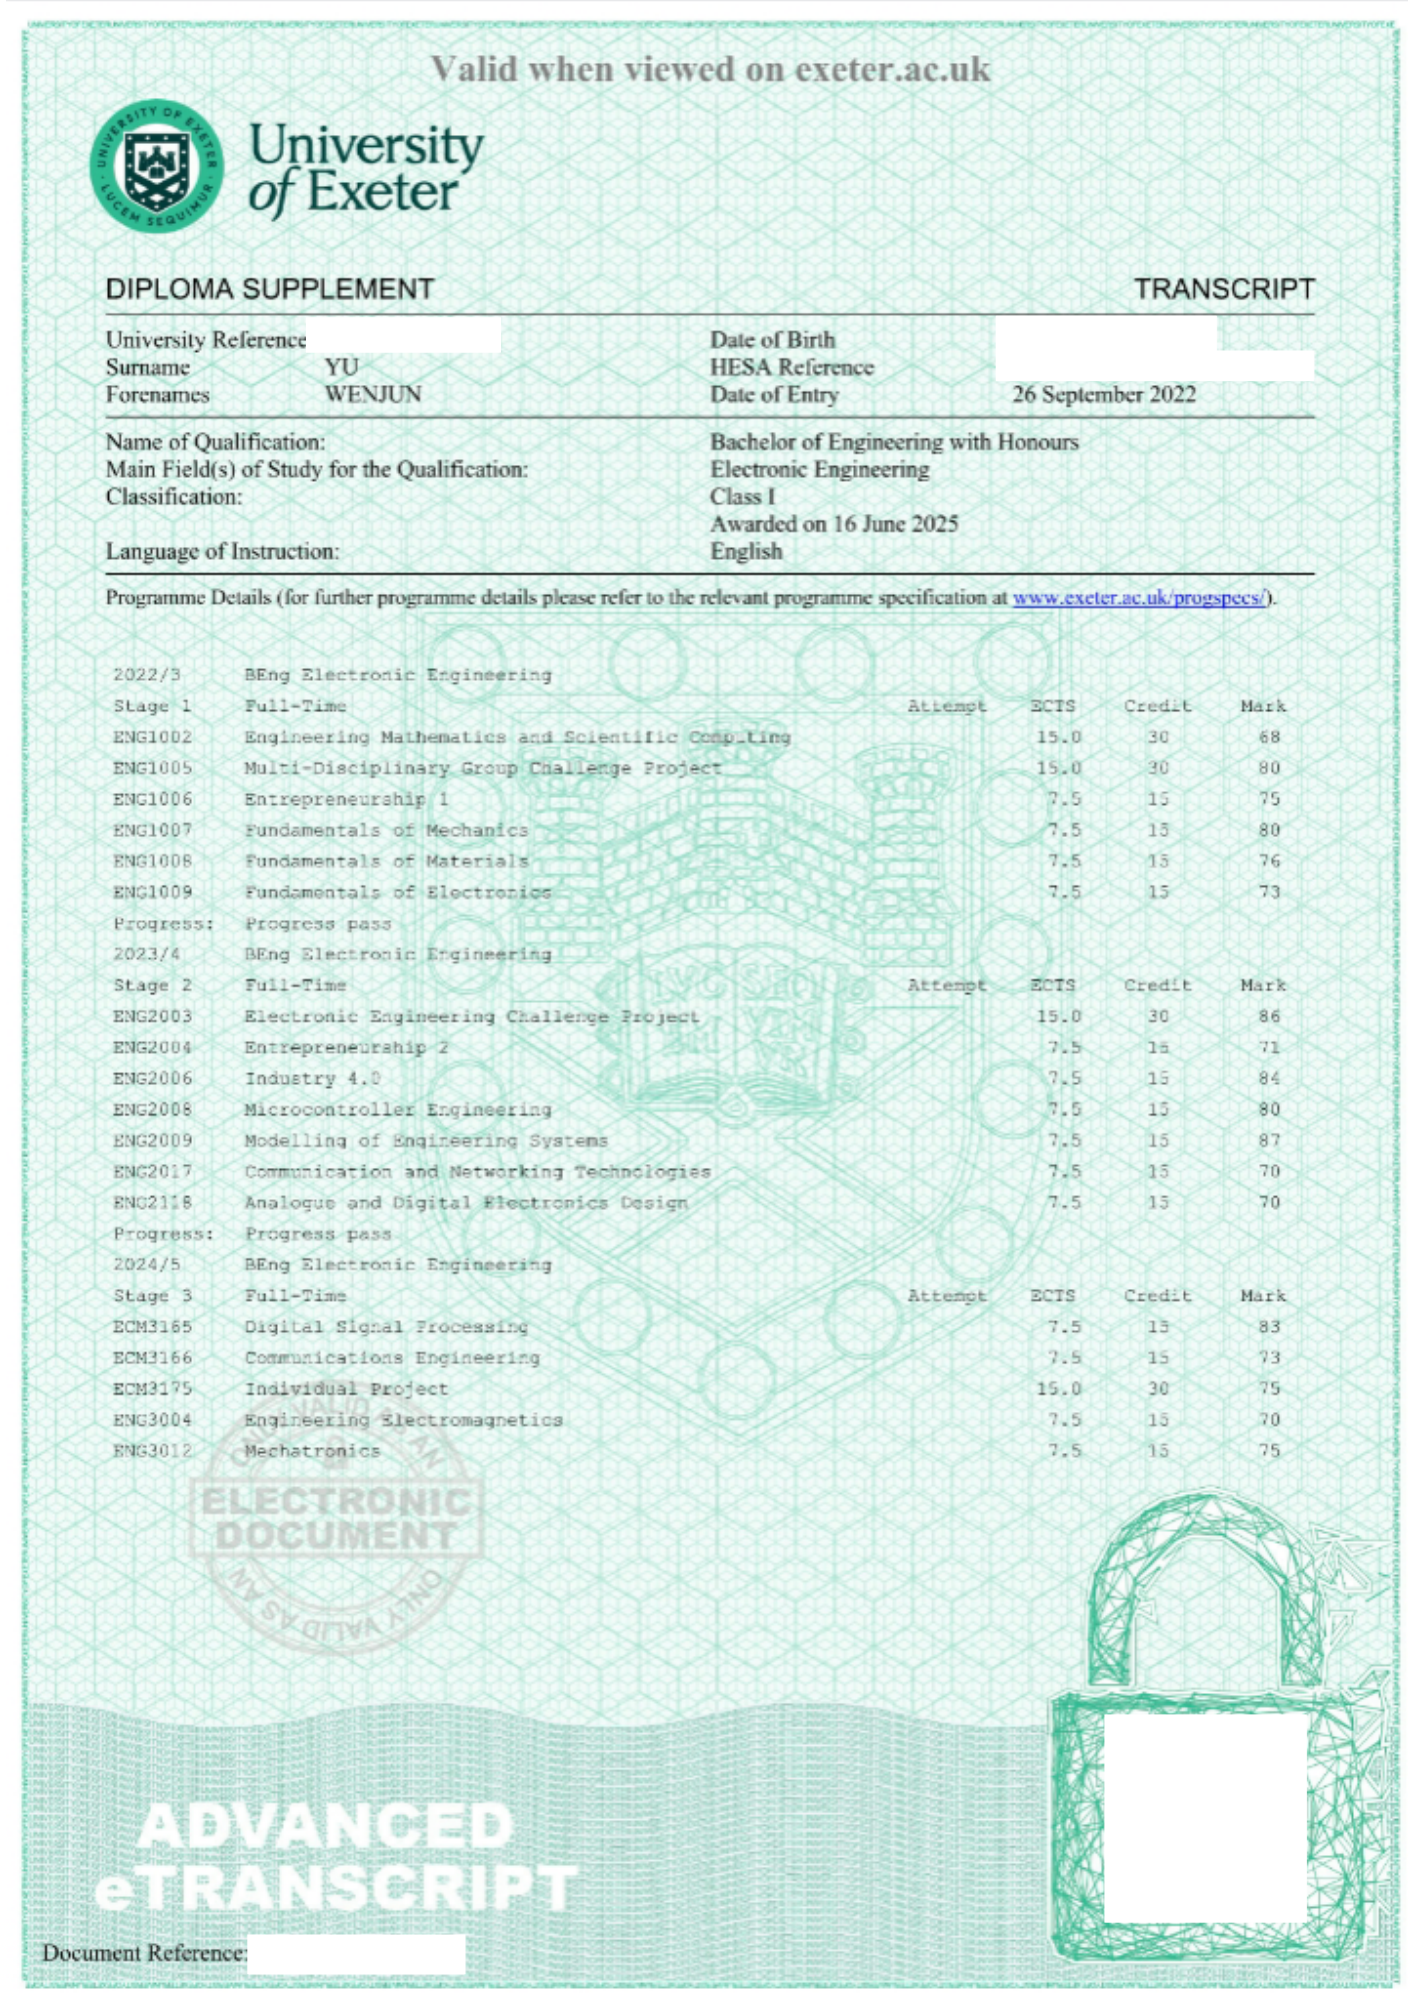
University of Exeter academic transcript (3 pages)
Open PDF: University of Exeter academic transcript
University of Exeter academic transcript, page 1; personal identifiers and verification codes removed where present.
Page 1
University of Exeter academic transcript, page 2; personal identifiers and verification codes removed where present.
Page 2
University of Exeter academic transcript, page 3; personal identifiers and verification codes removed where present.
Page 3

Personal identifiers hidden in displayed copies.

Certificates

SOLIDWORKS CAD Design Associate

Dassault Systèmes

SOLIDWORKS certification (1 page)
Open PDF: SOLIDWORKS certification
SOLIDWORKS certification, page 1; personal identifiers and verification codes removed where present.
Page 1

Personal identifiers hidden in displayed copies.

Experience

Contract Development Engineer
Hatherleigh Fish BarJul 2025 to Sep 2025
Low Voltage Engineer
XRacingSep 2024 to Aug 2025
Machinist
ND Precision ProductsJul 2021 to Aug 2021